EgoCPT, step by step
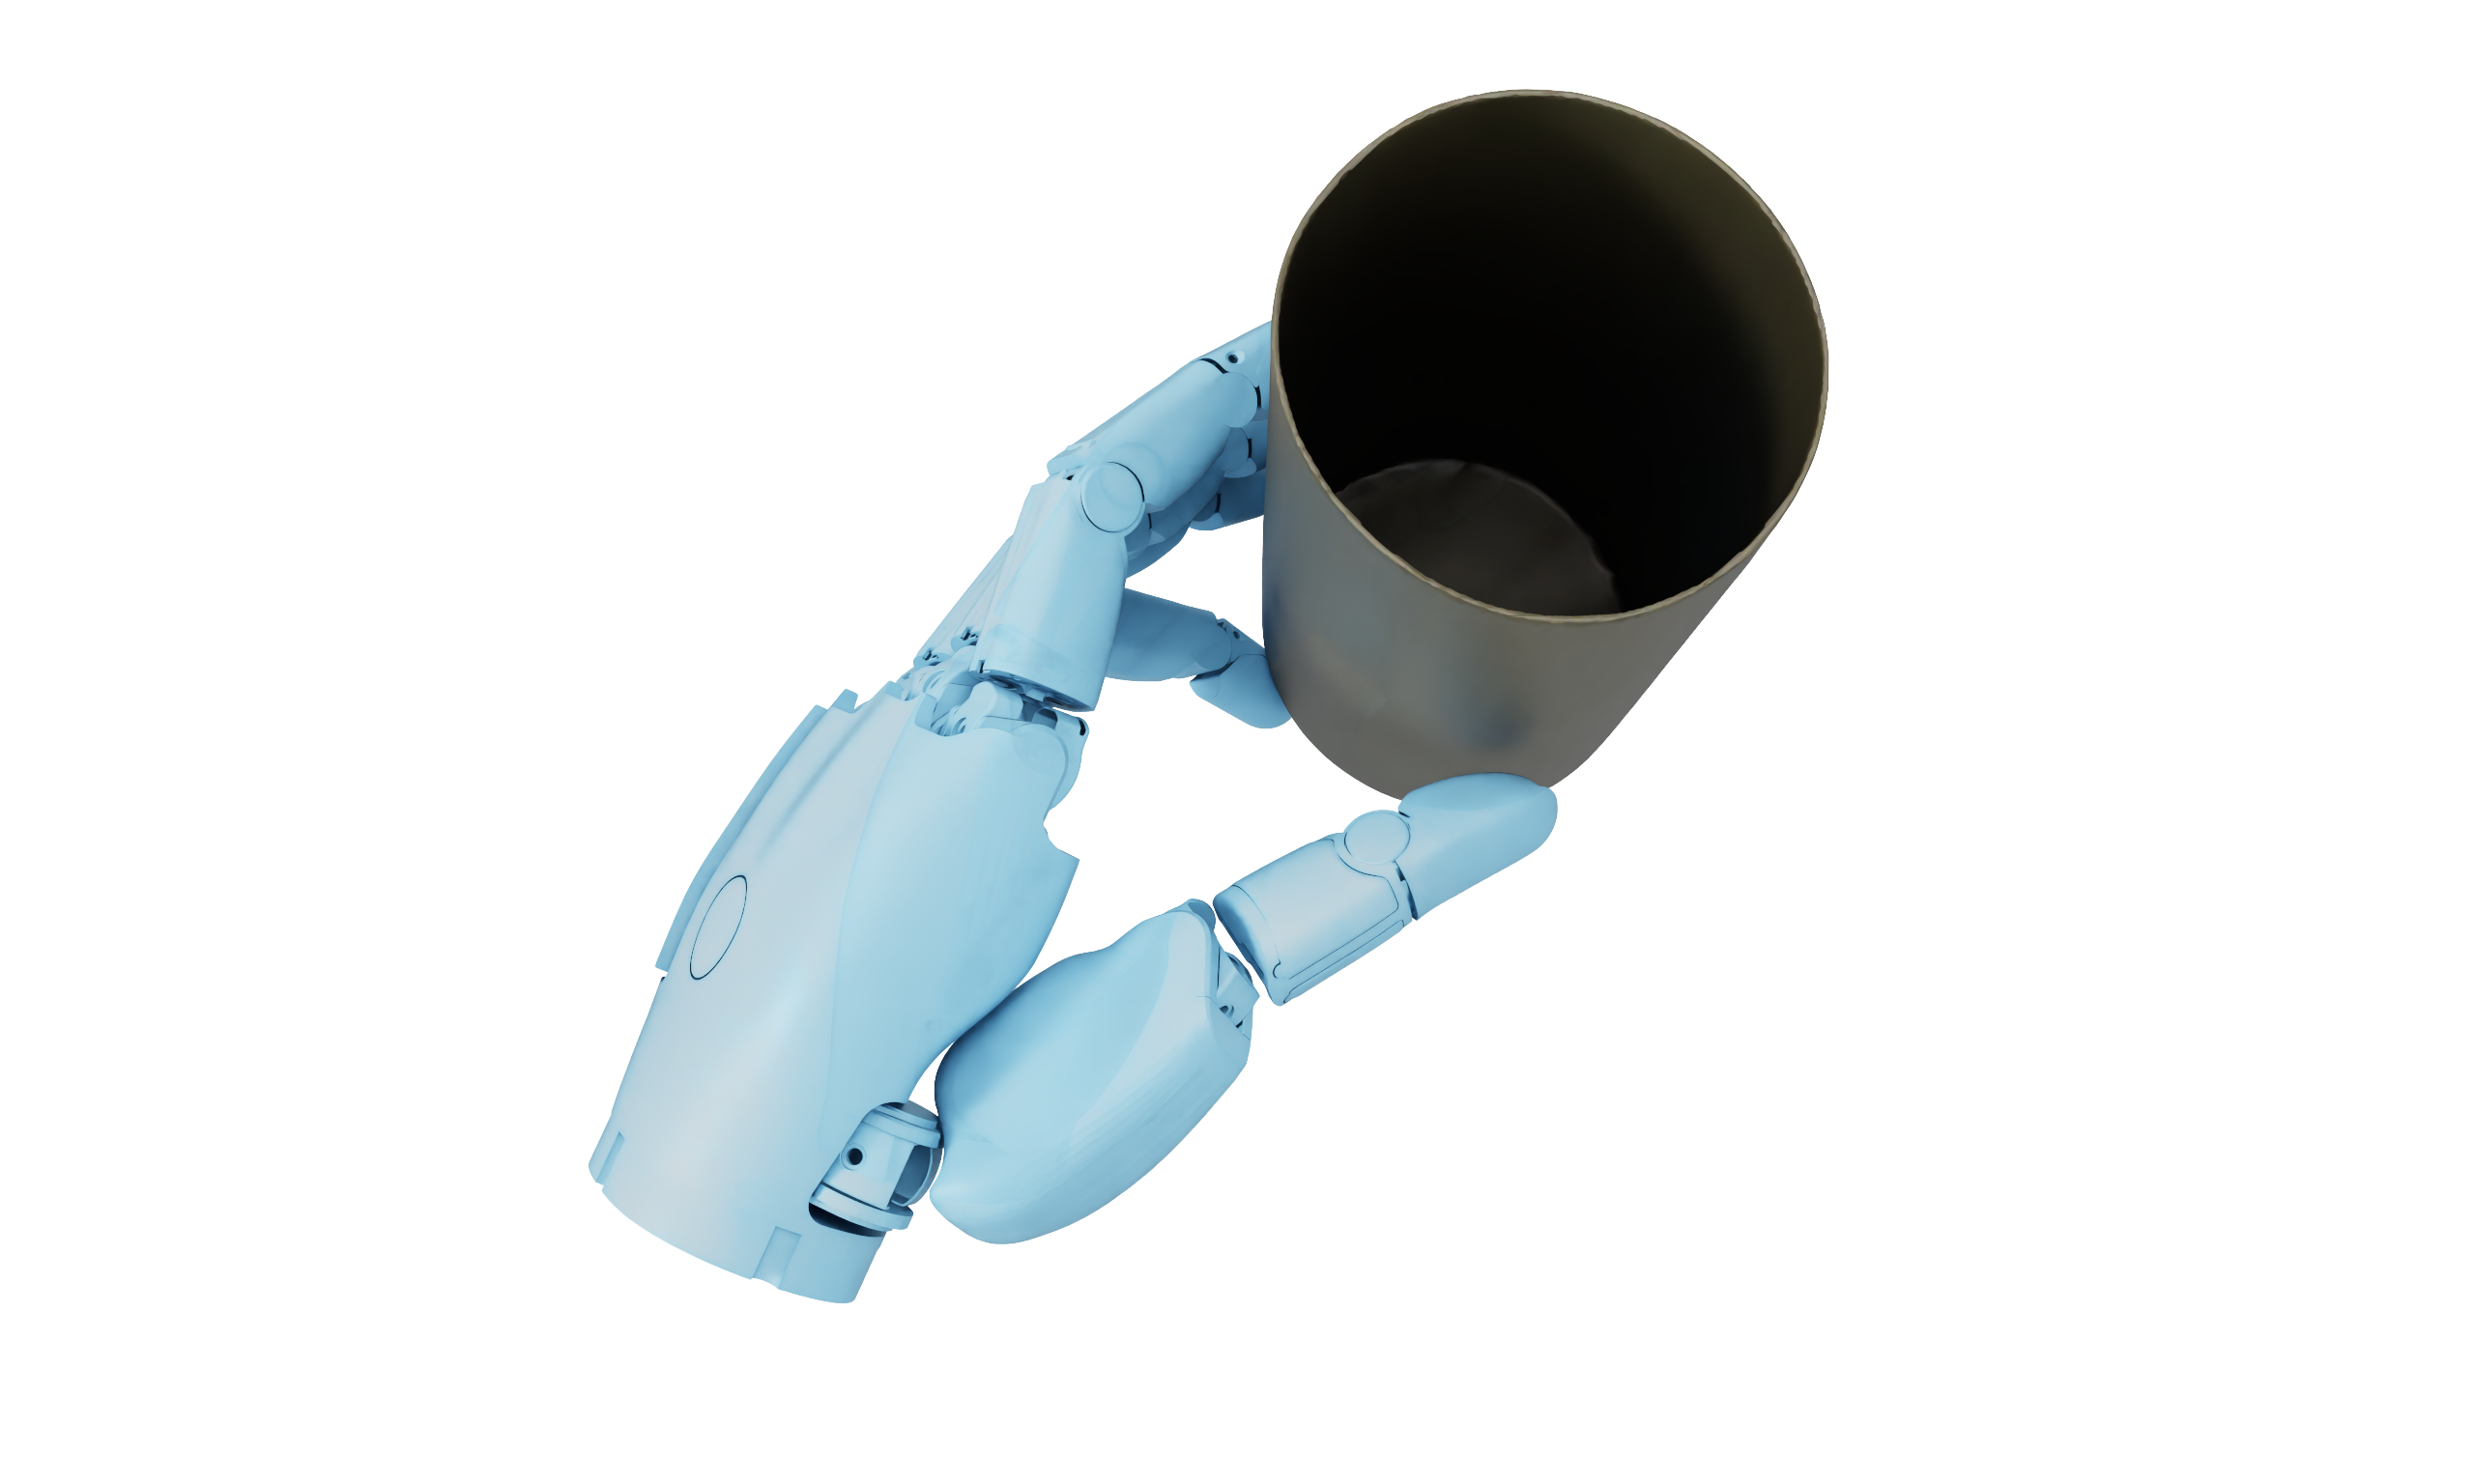
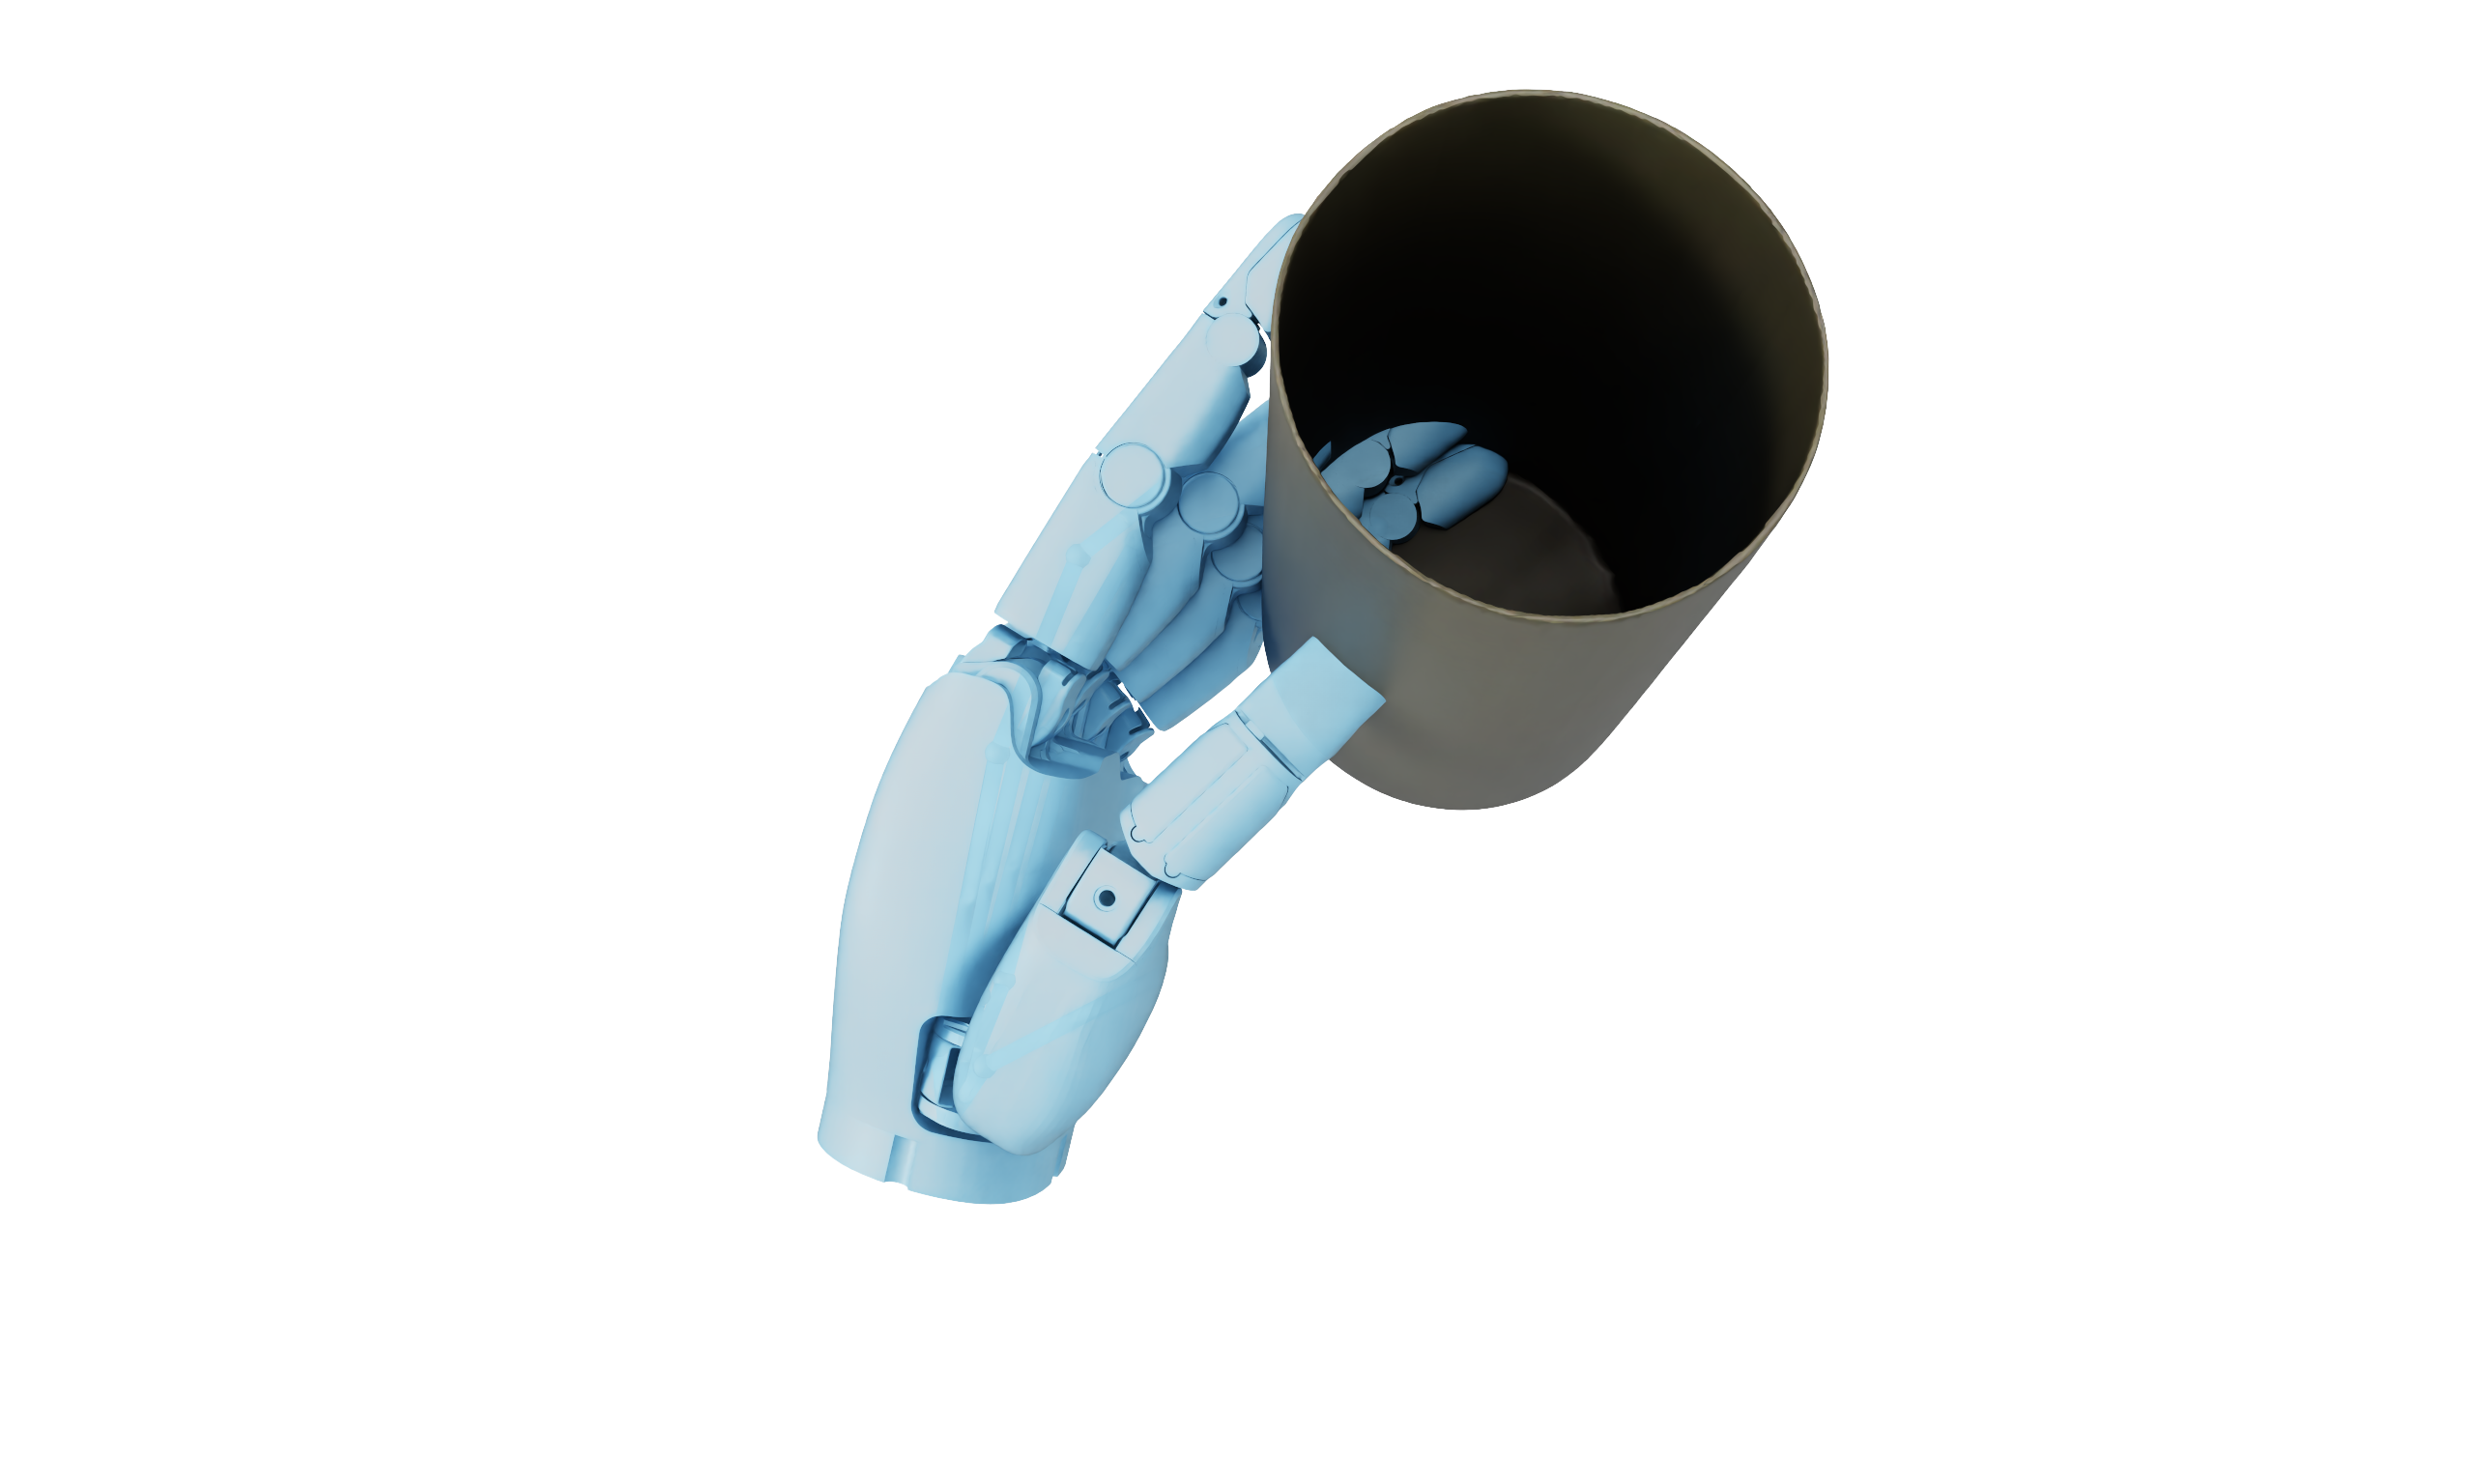
One pouring demonstration. Four stages.
Switch stages to compare the same moment. Drag the timeline to explore.
While expert demonstrations on real robots are difficult to collect, human ego-centric videos are easy to collect and abundant on the internet. However, learning dexterous manipulation policies from human videos remains challenging—one of the most important challenges being the difficulty of reconstructing physically grounded robot trajectories due to the large embodiment gap.
In this paper, we propose EgoCPT, a novel paradigm for learning high-quality retargeted dexterous hand trajectories directly from an ego-centric video, which can then be deployed directly on real robots. The only inputs to our method are an ego-centric RGB video and a reference hand pose trajectory, which can be easily obtained through off-the-shelf software or specialized cameras during recording. Our method is particularly robust to noisy hand poses attributed to our novel contact-aware optimization framework, which iteratively optimizes the contact points between the robot hands and objects.
Across five manipulation tasks, our method achieves overall success rates of 67.3% on noisy EgoDex hand-pose reconstructions and 92.0% on high-quality TACO reconstructions collected using motion-capture hardware, outperforming multiple baselines on both benchmarks.
Drag the dividers to see how EgoCPT improves hand–object reconstruction. Each pair shows the same moment from the same view.
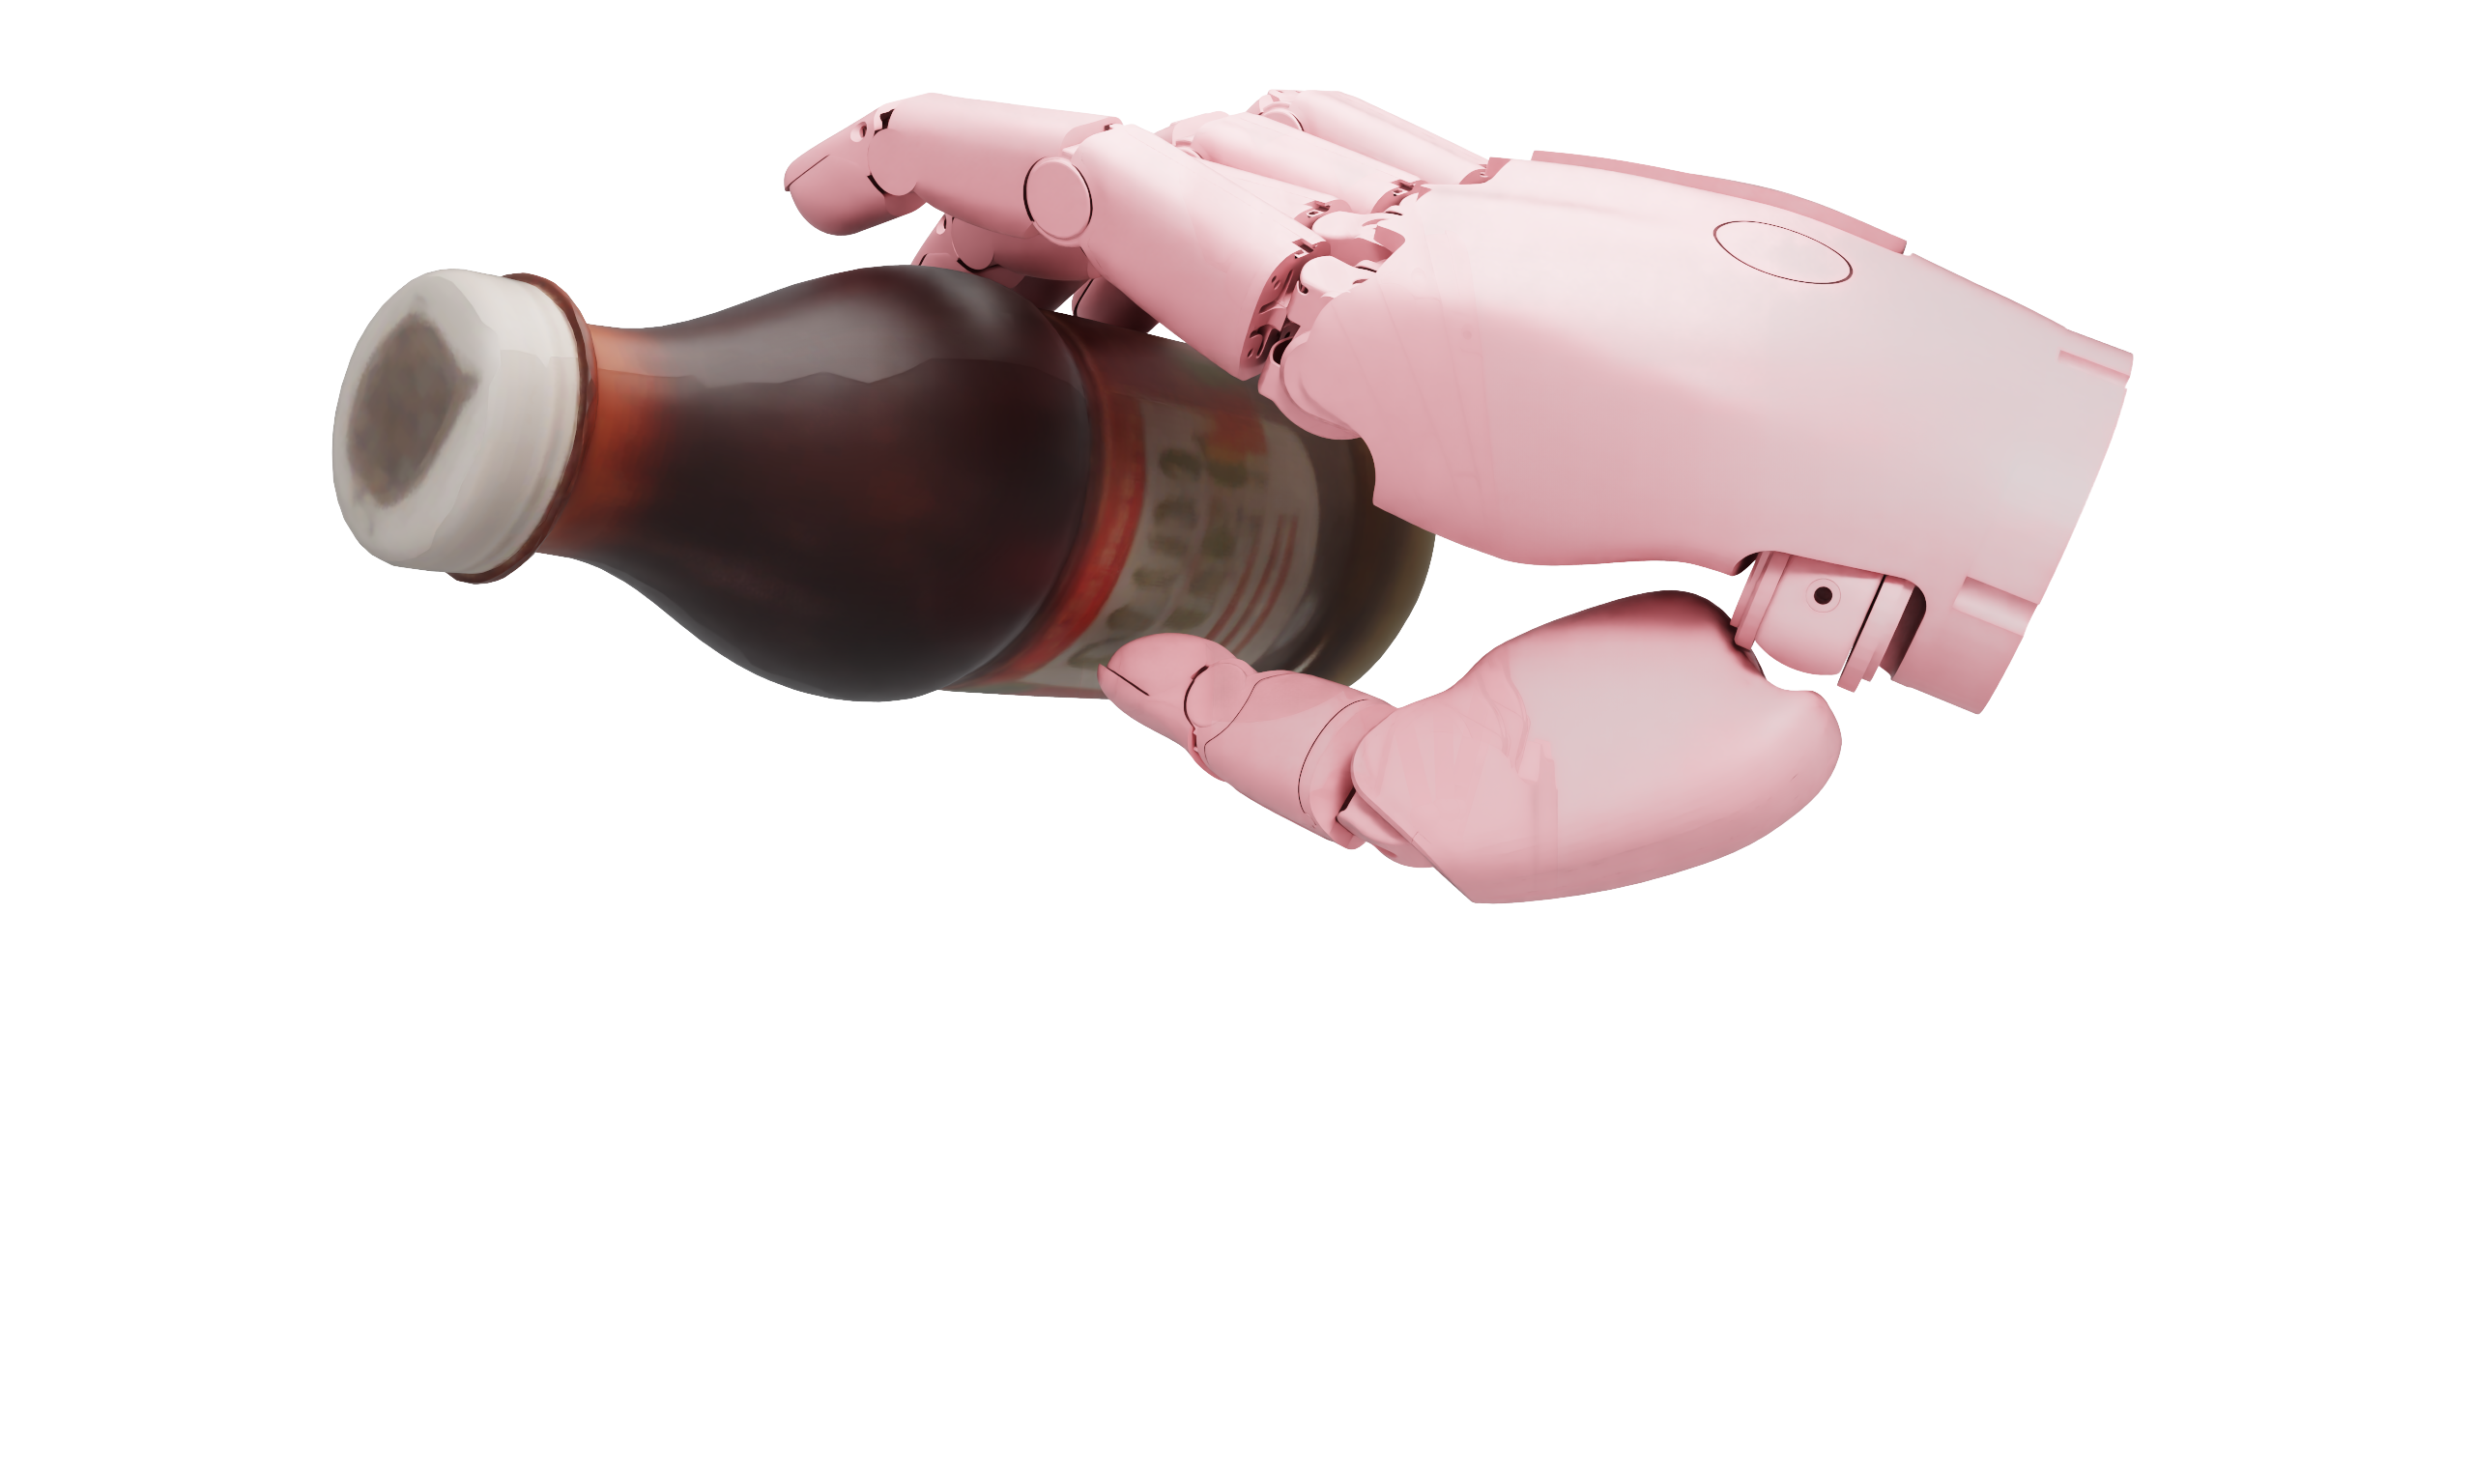
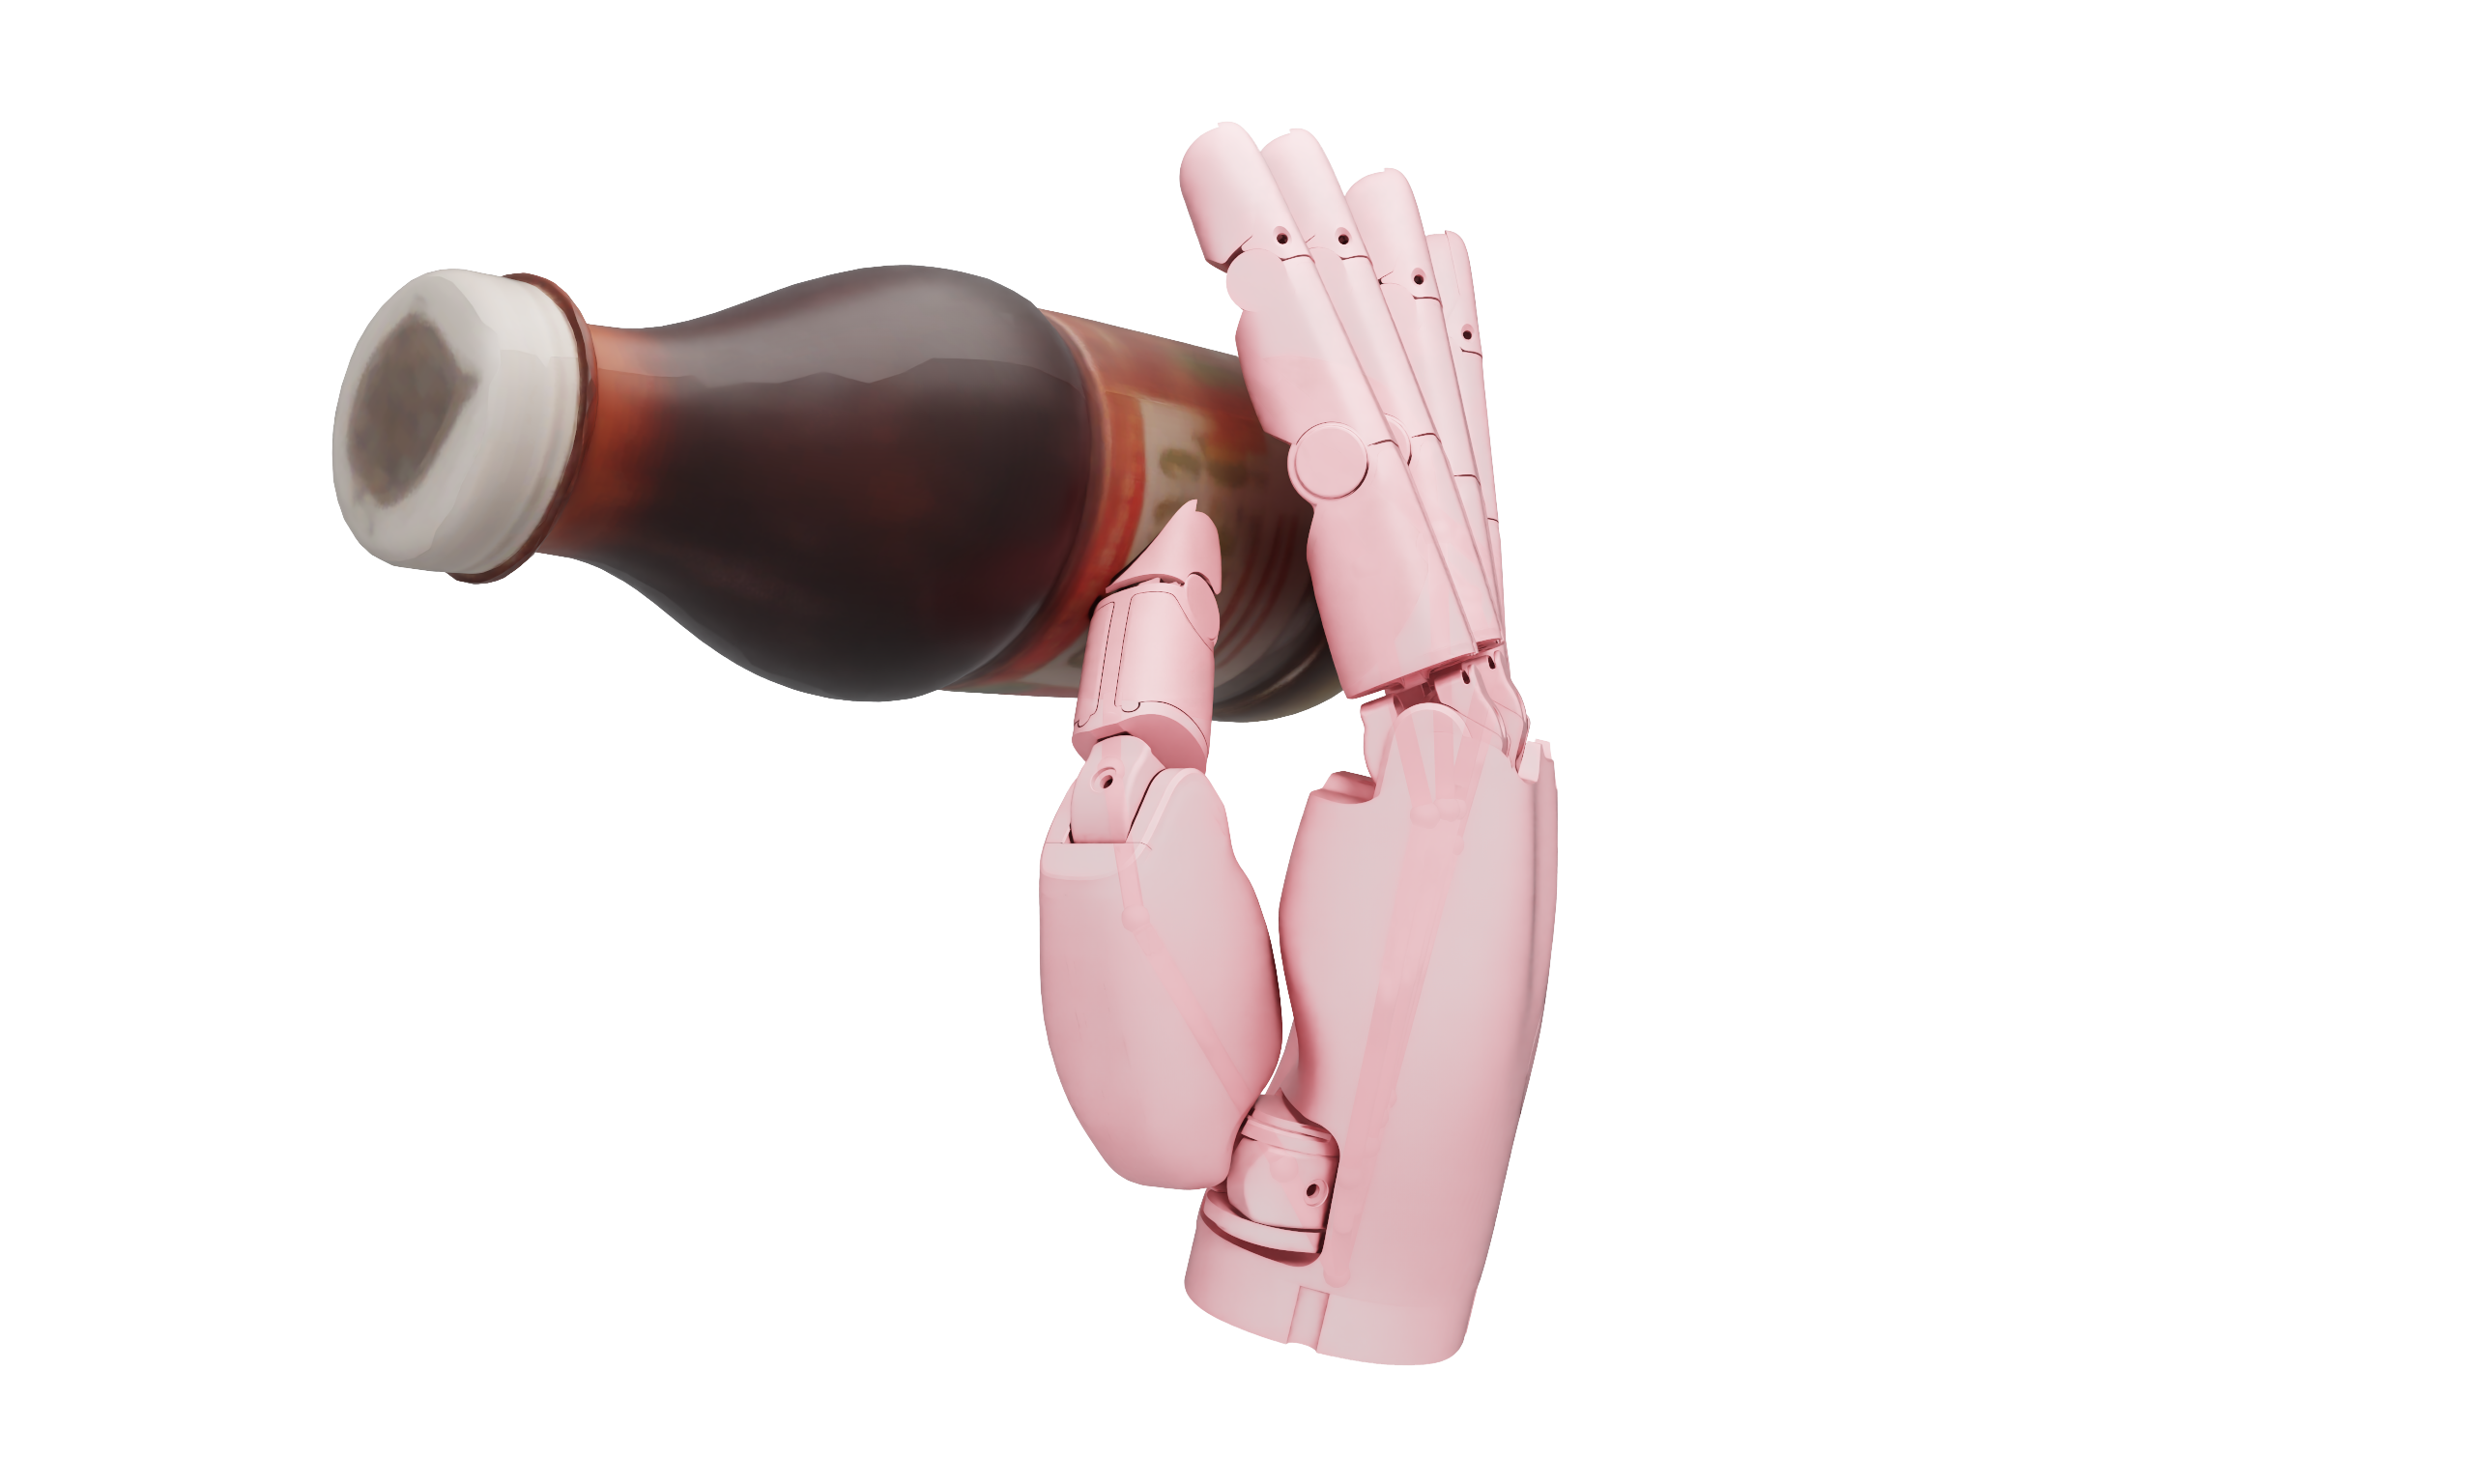
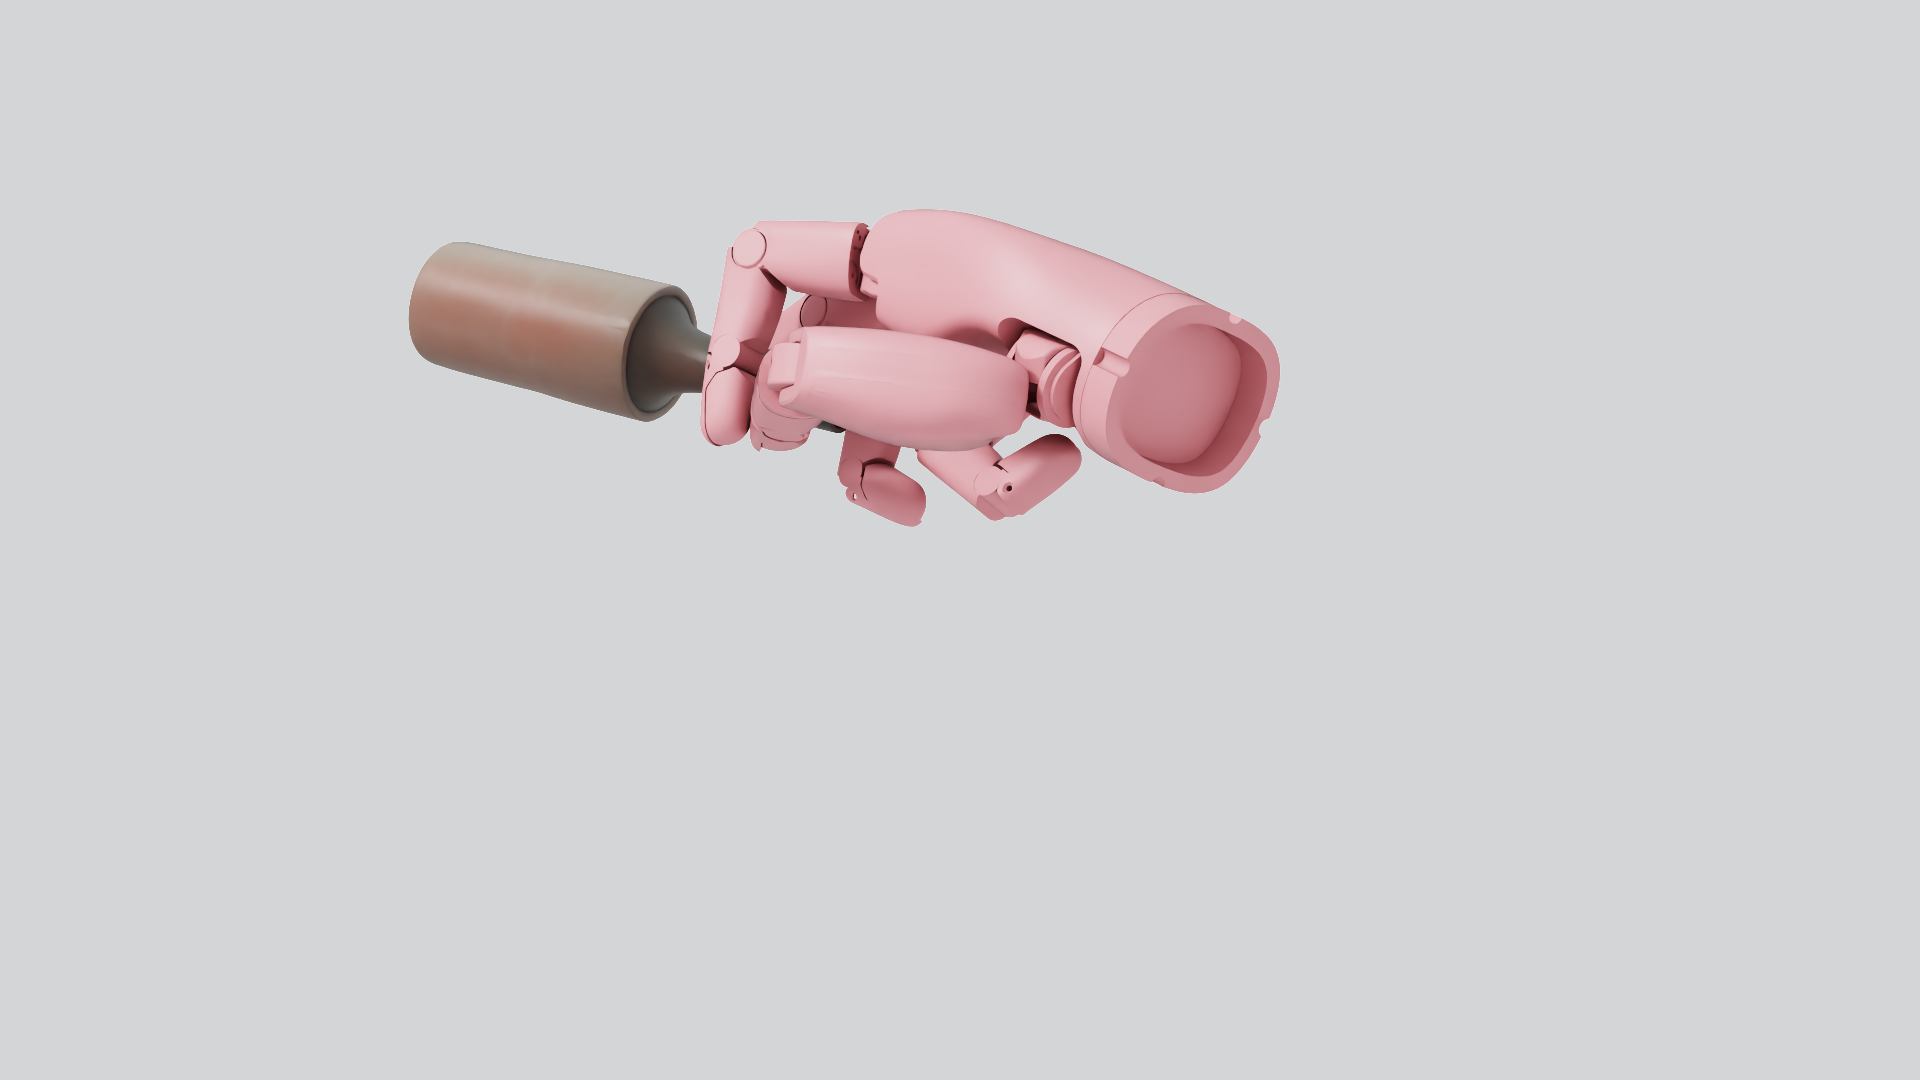
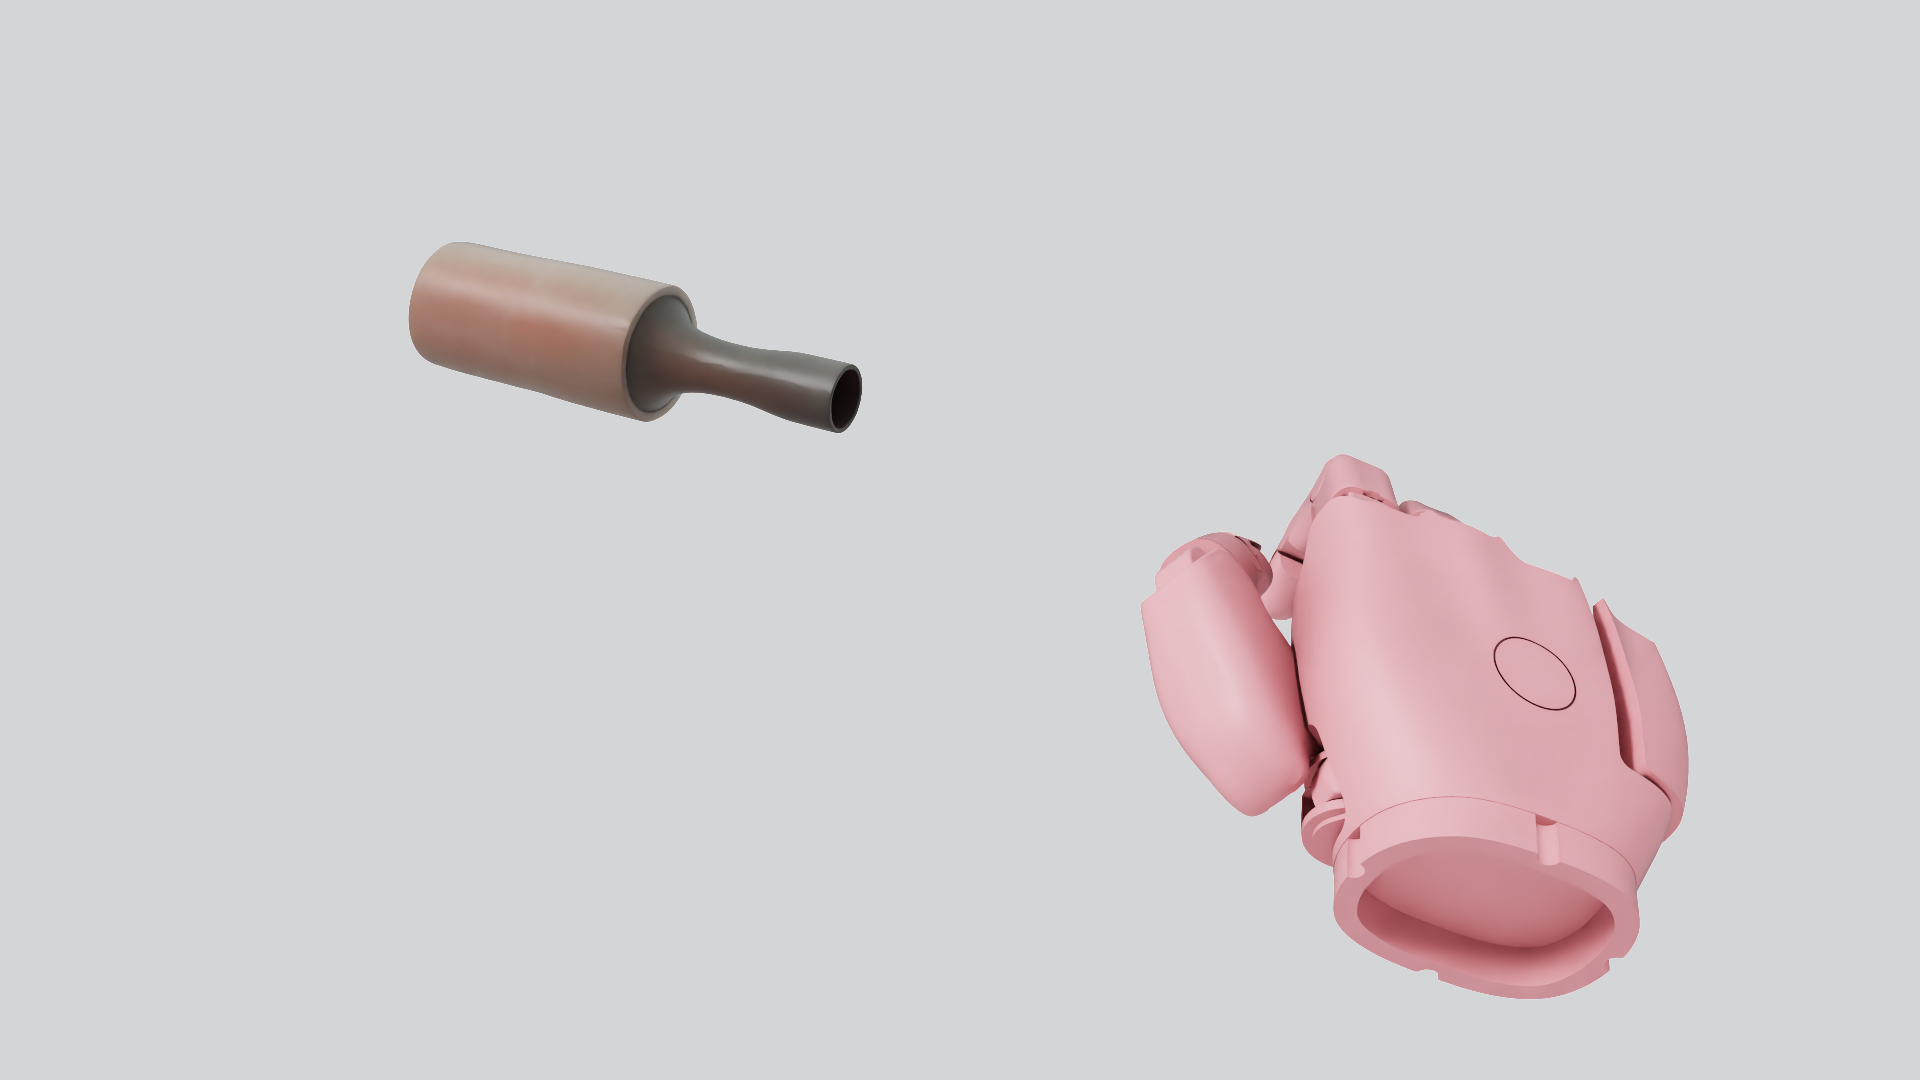
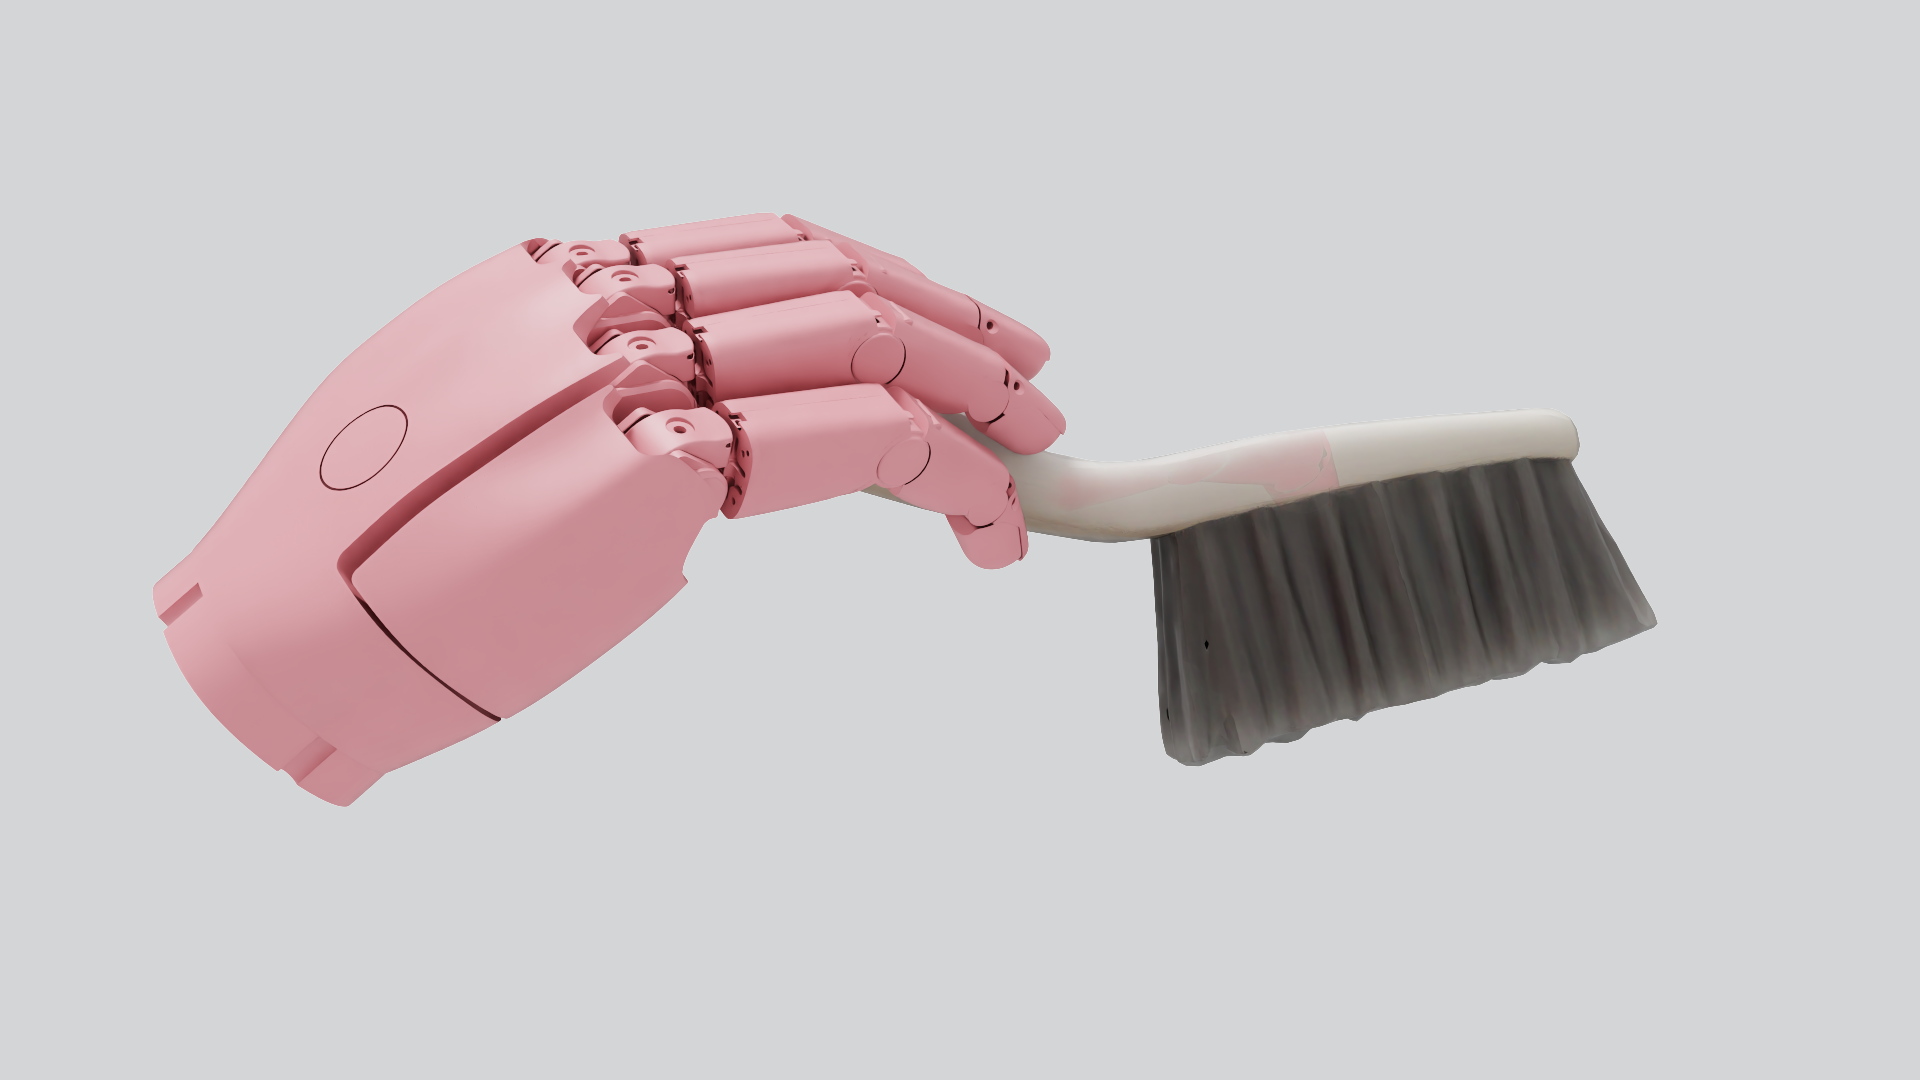
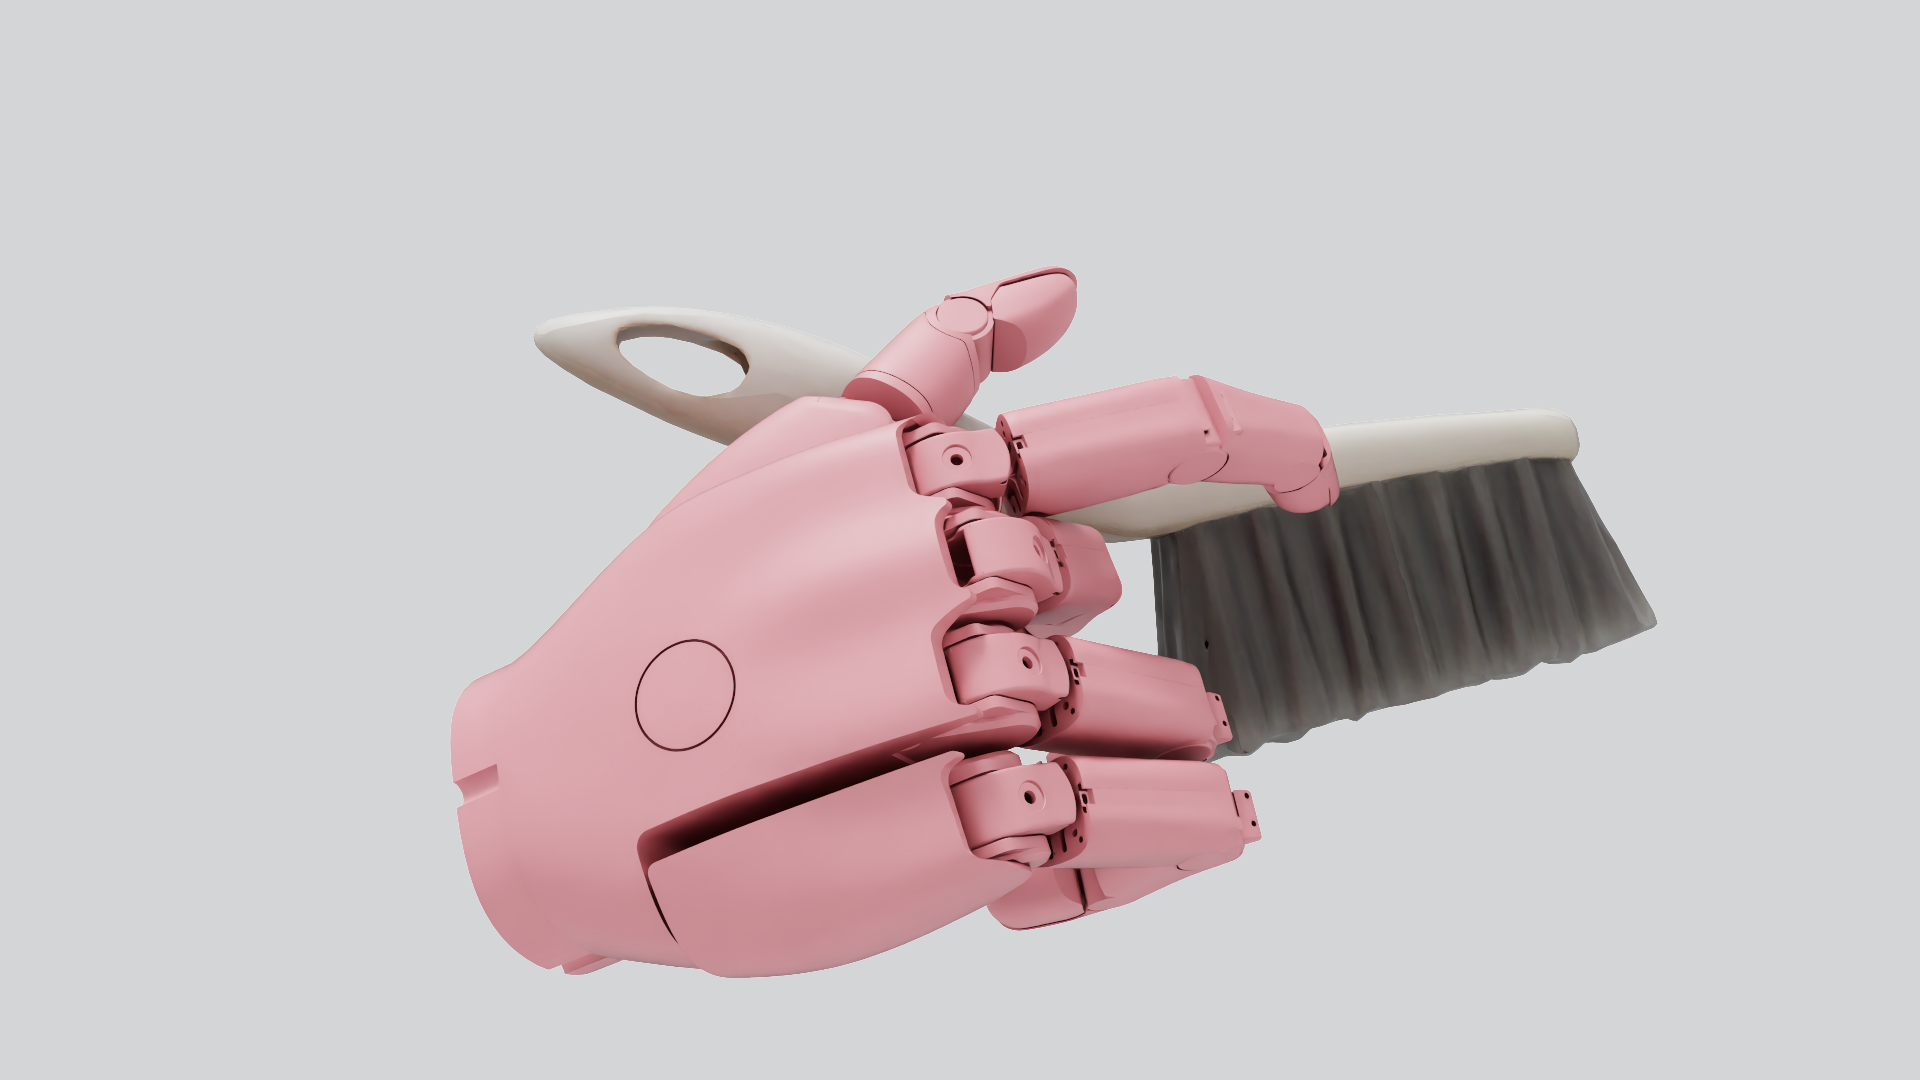
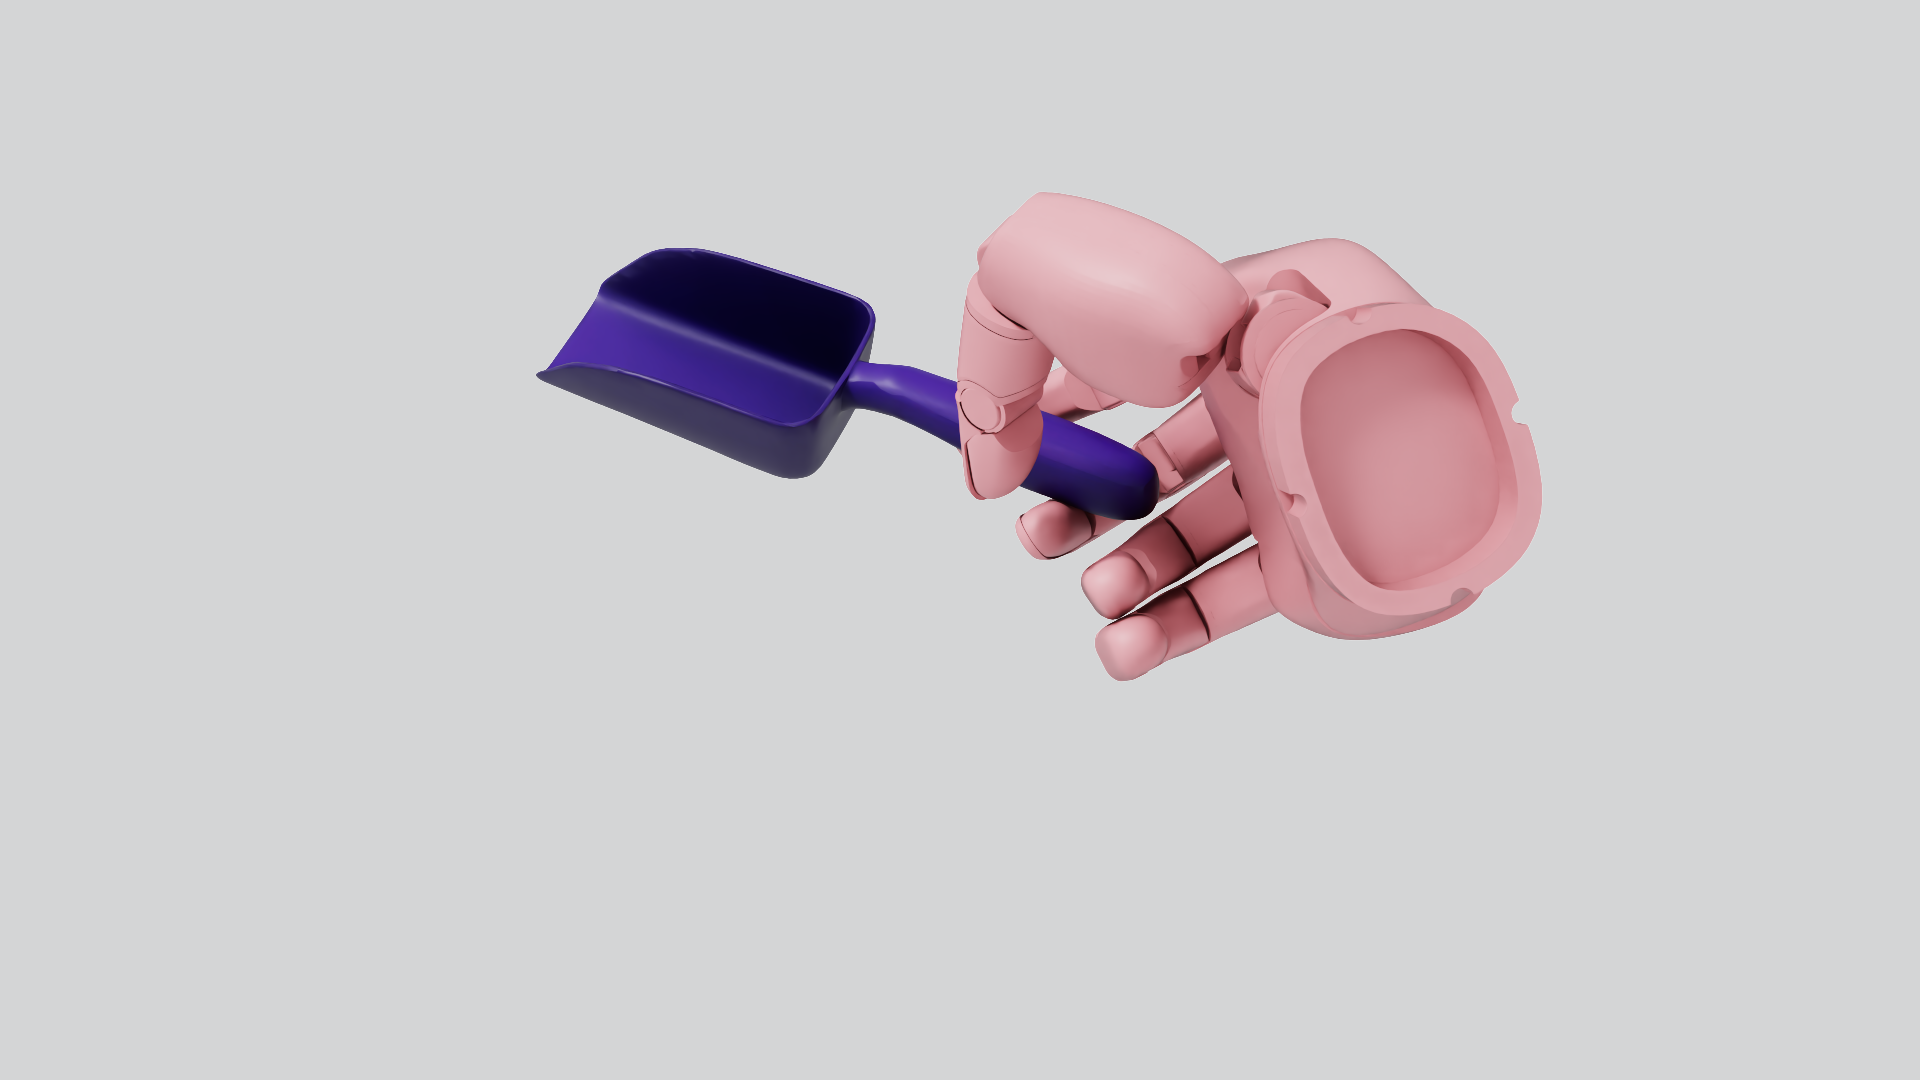
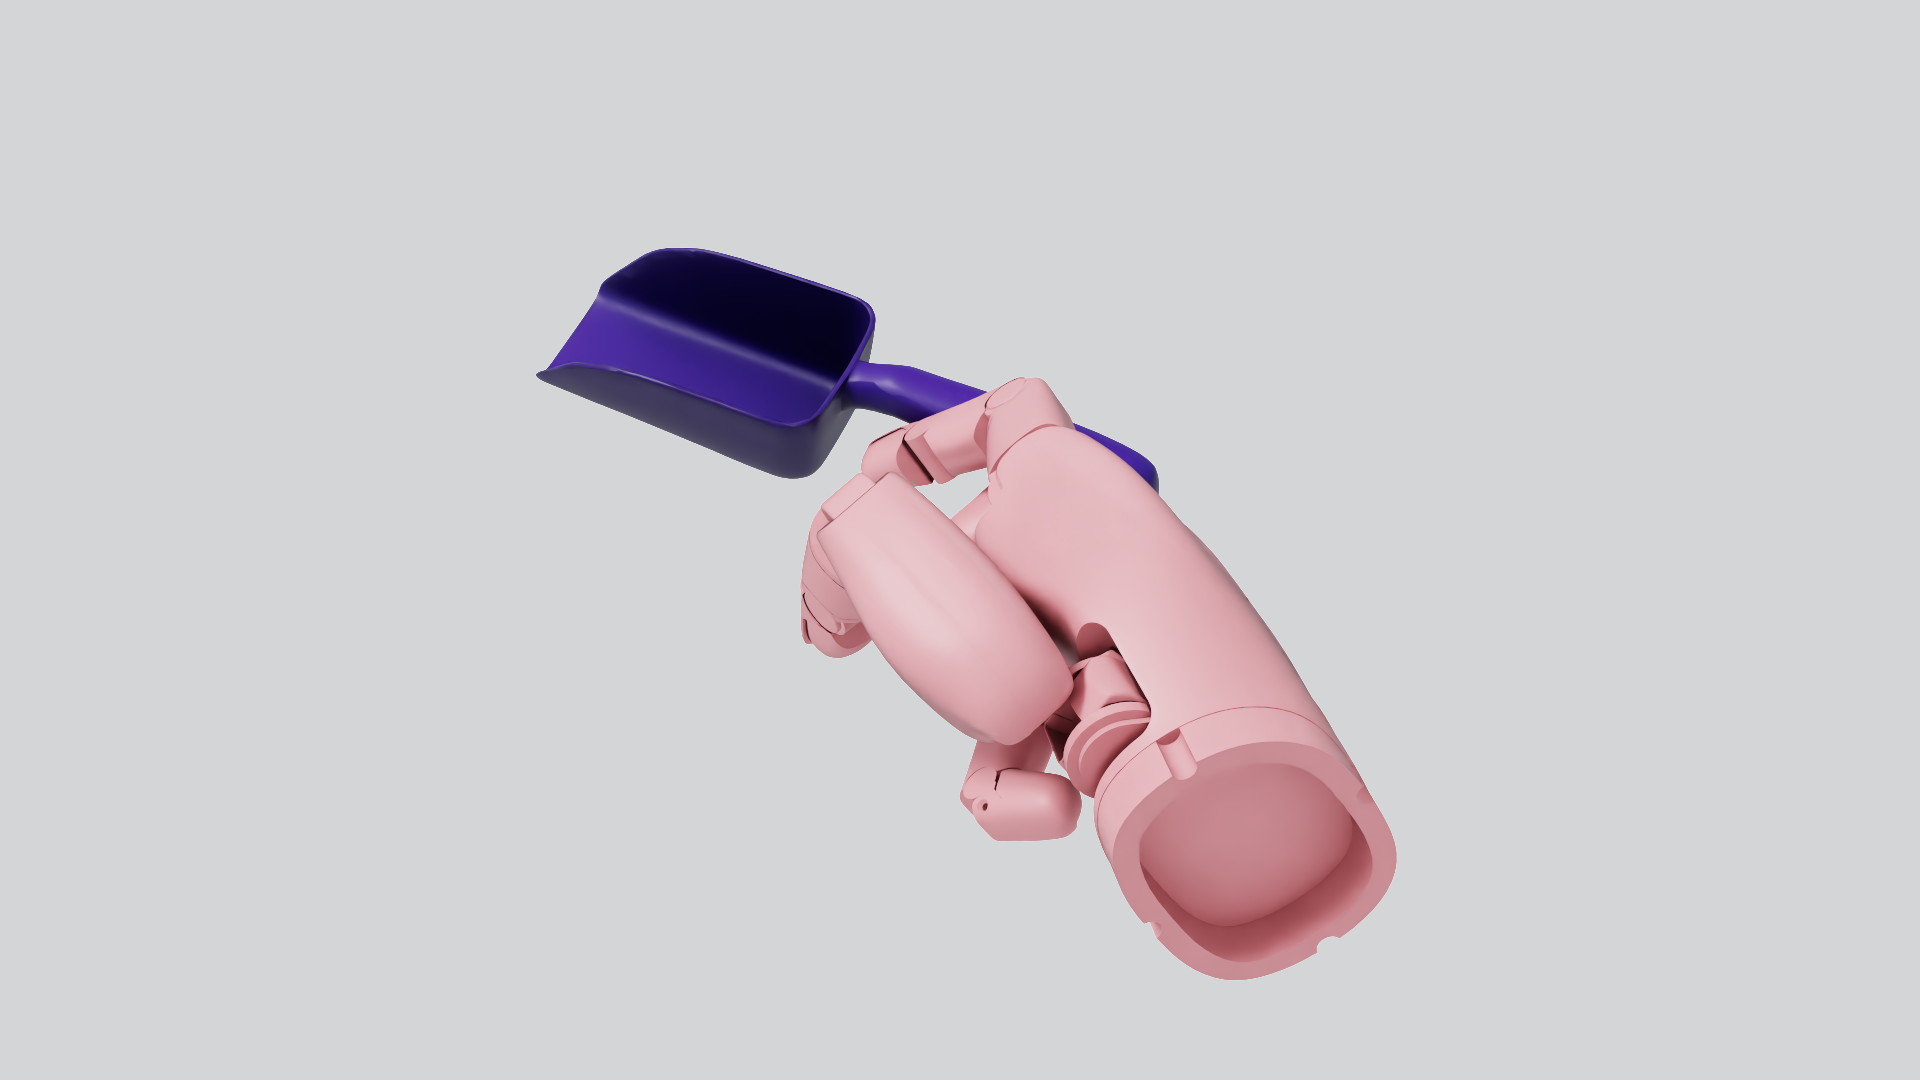
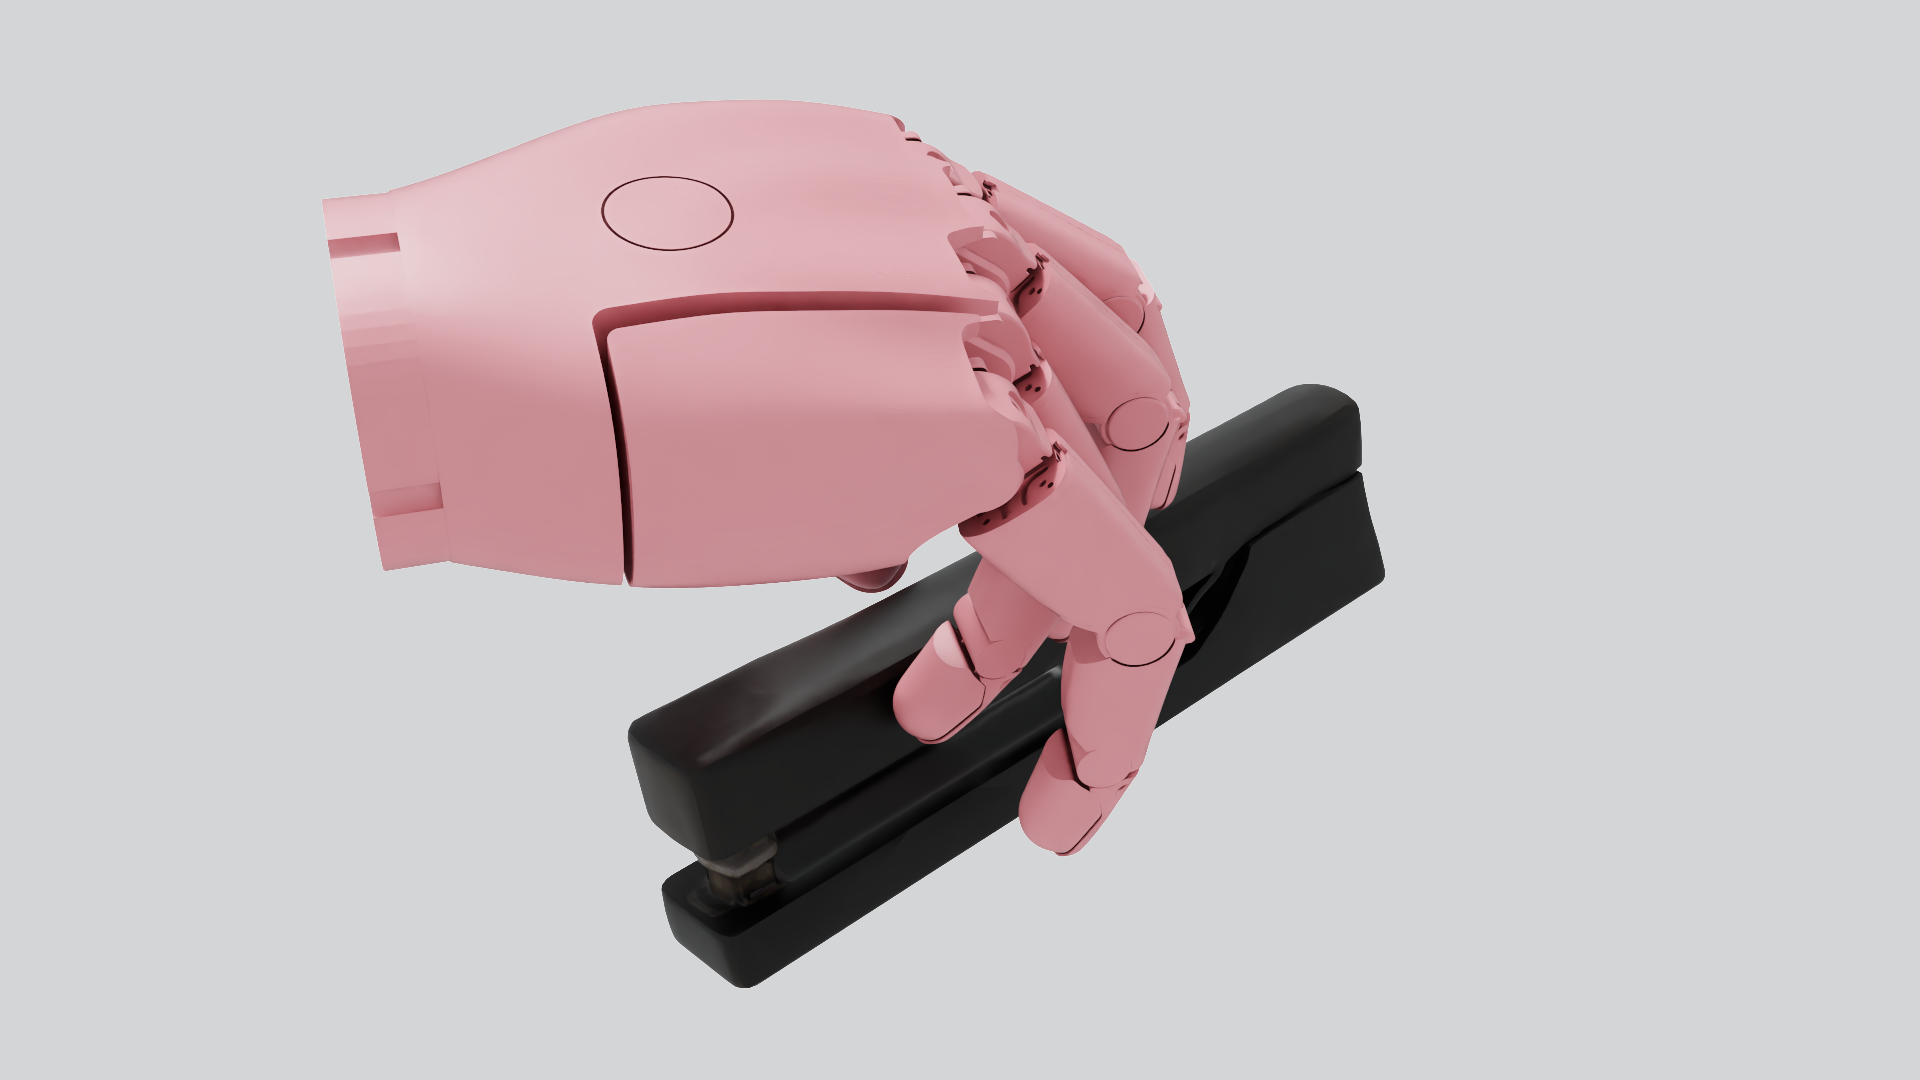
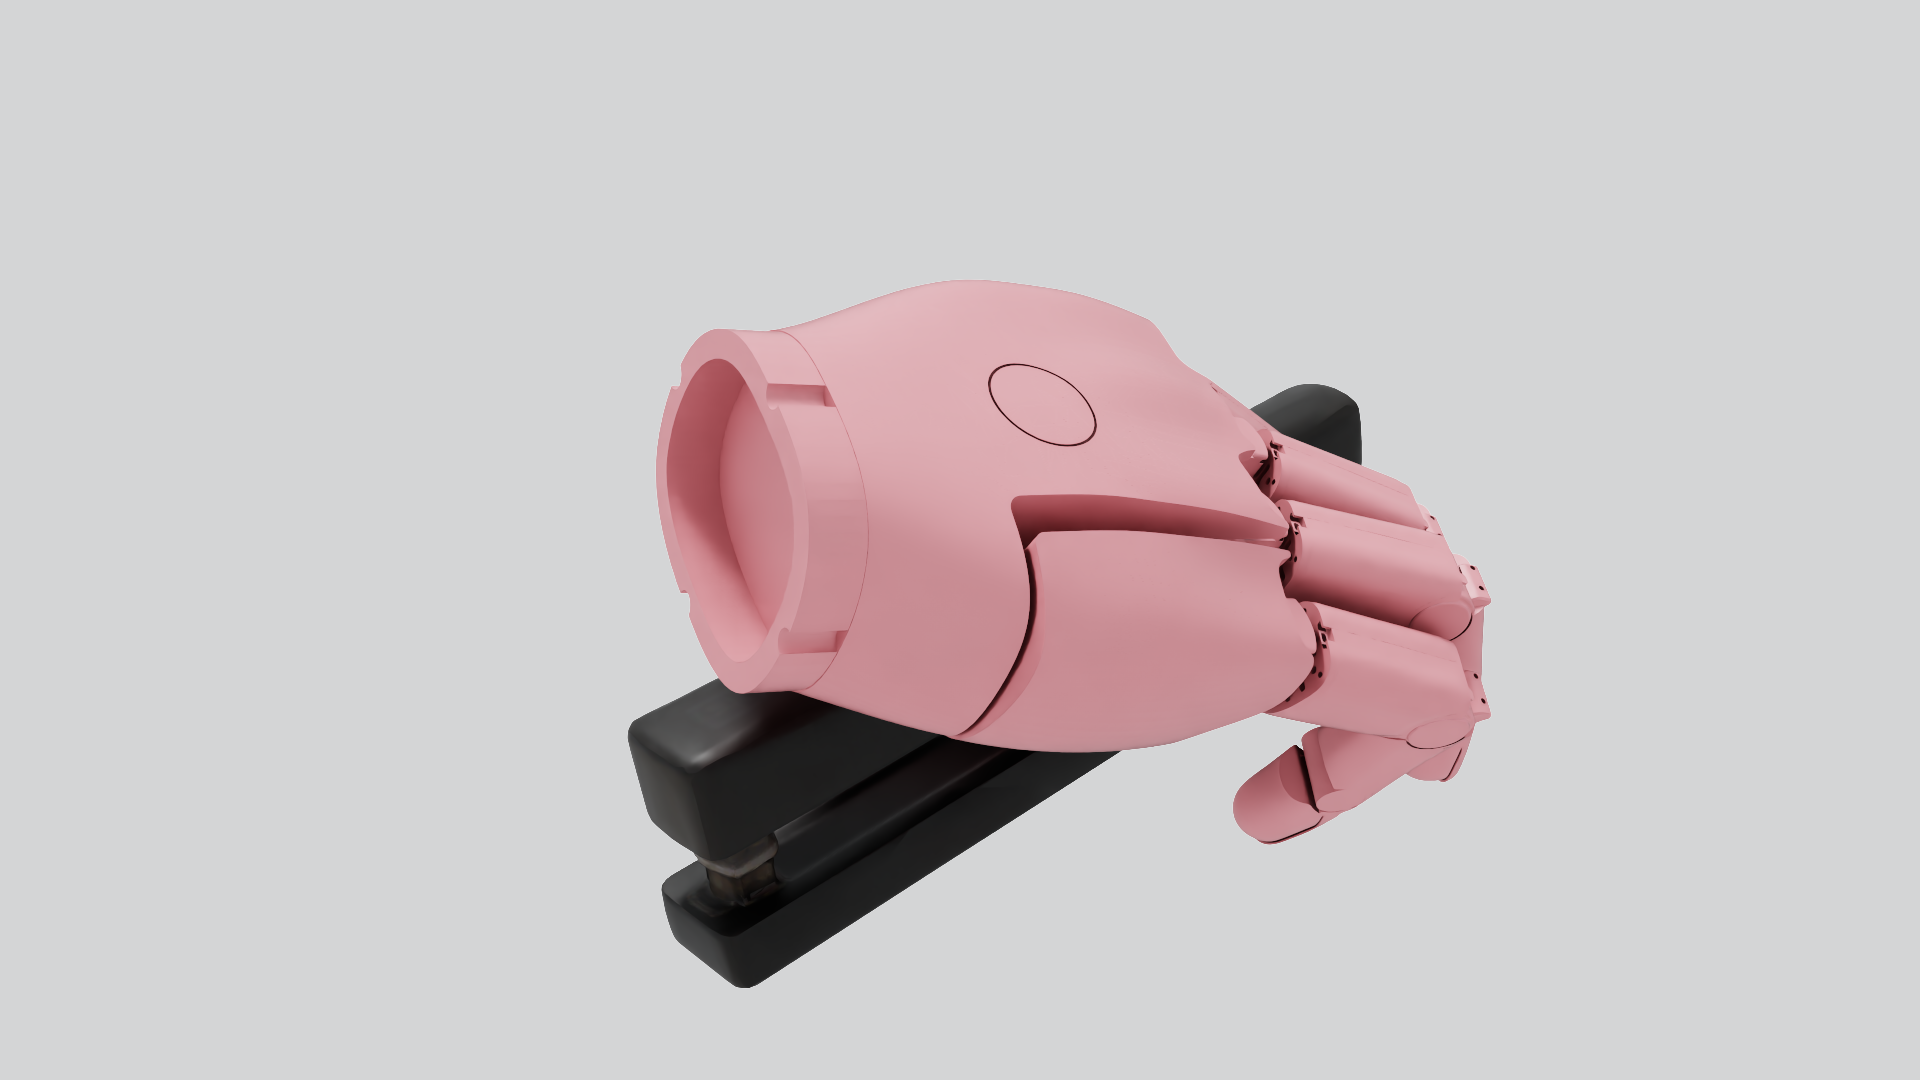
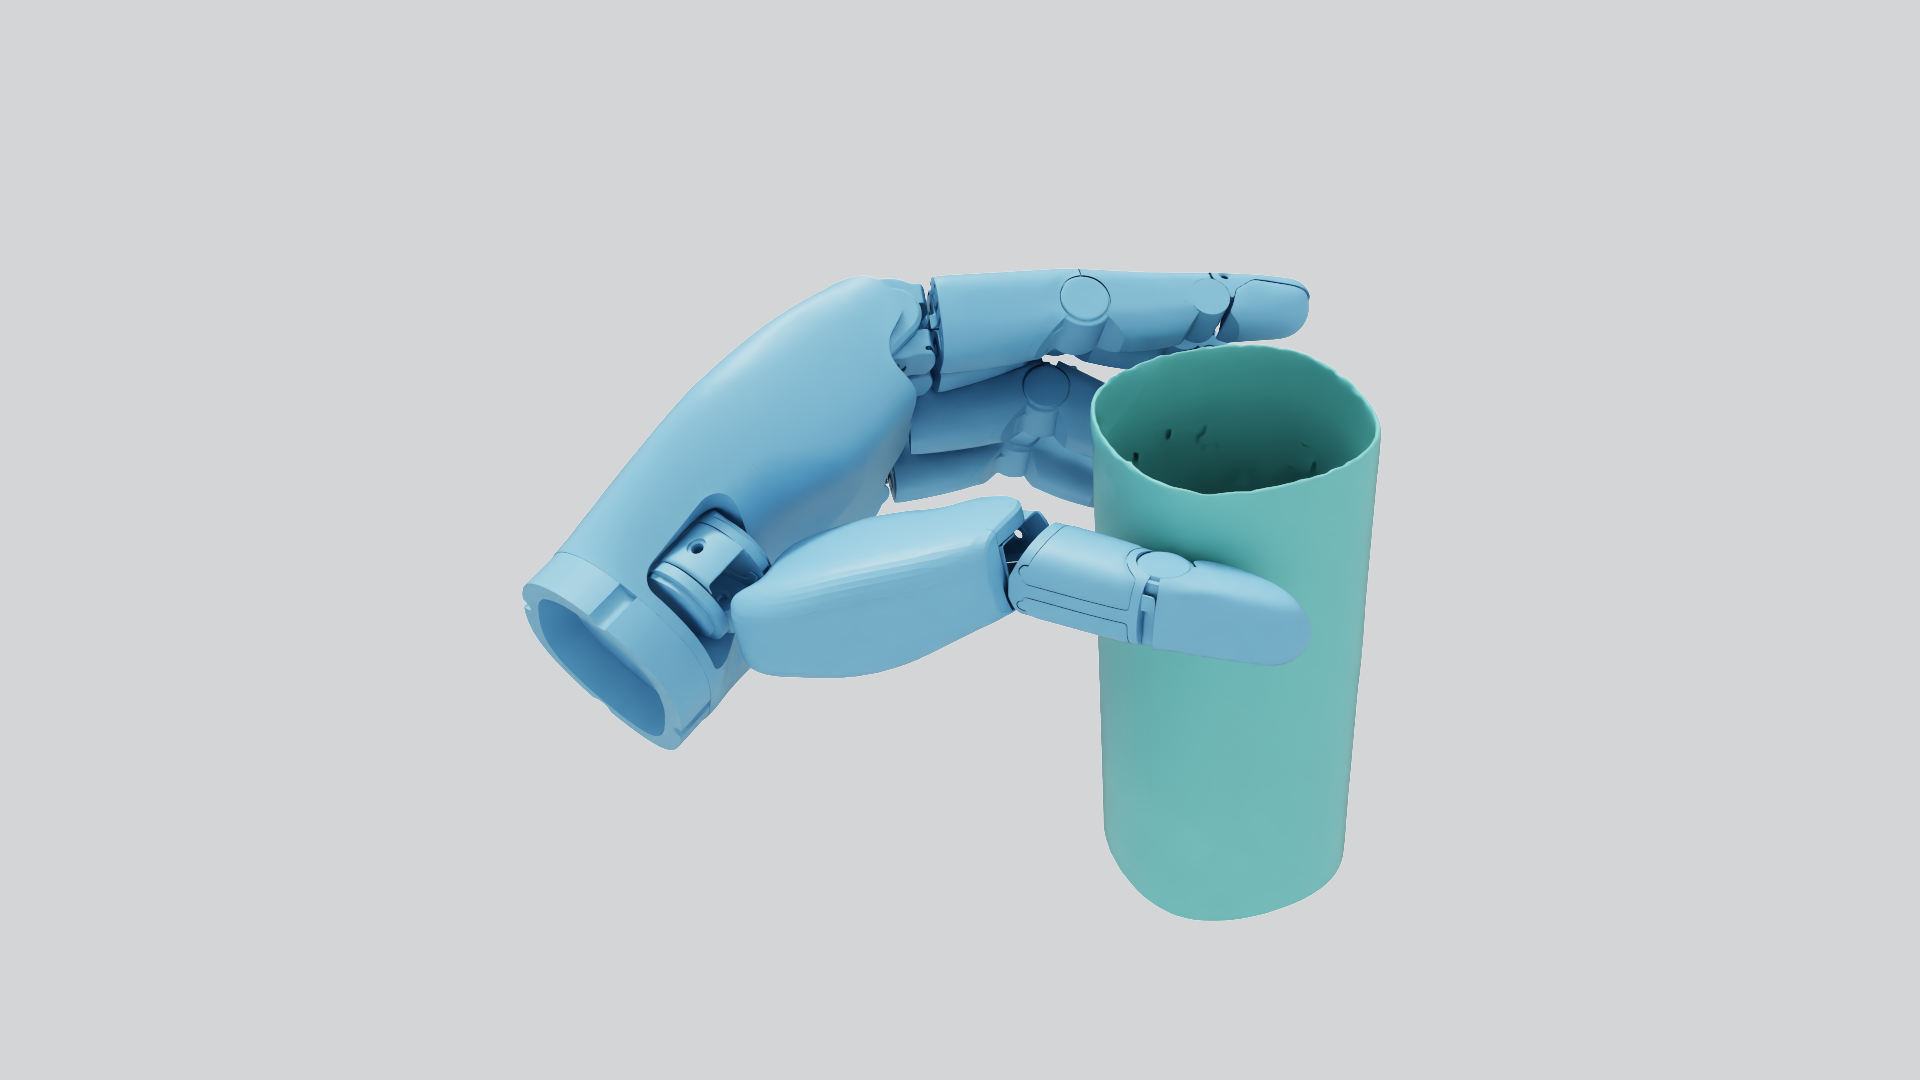
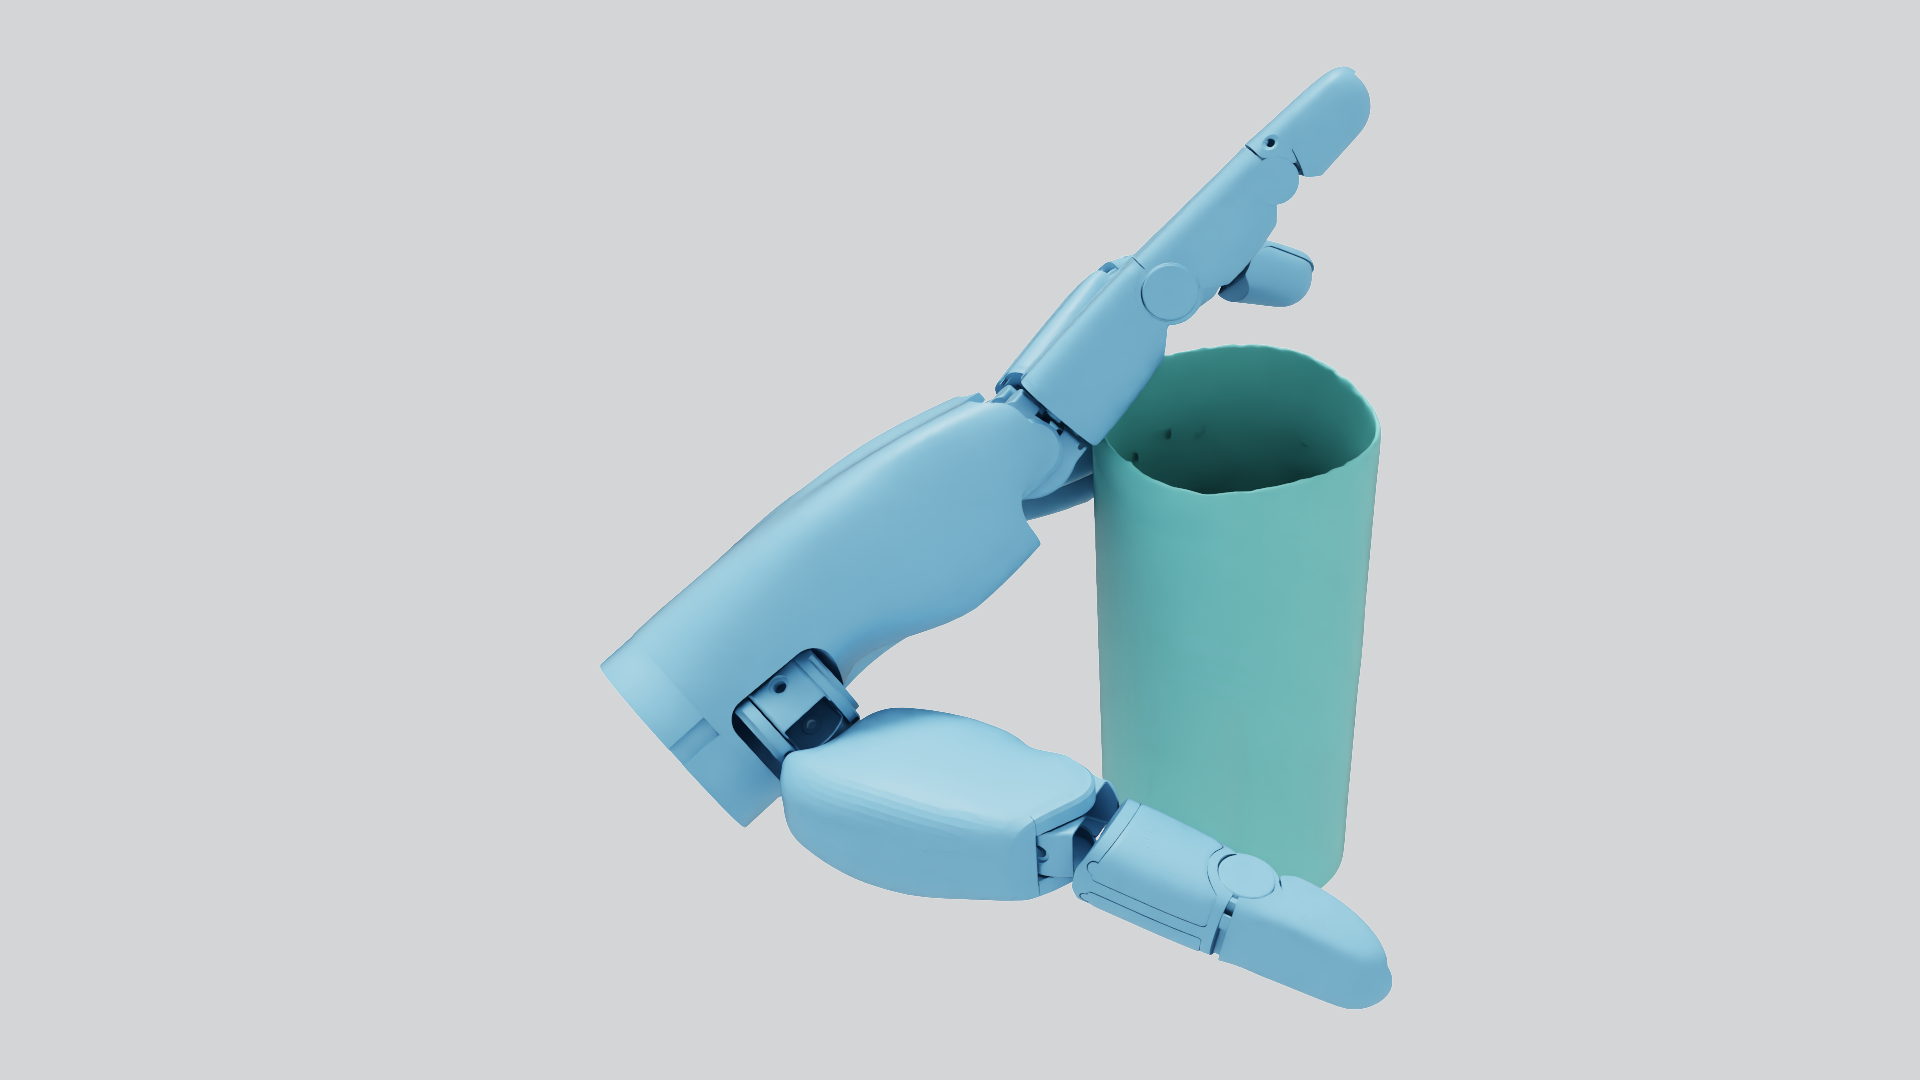
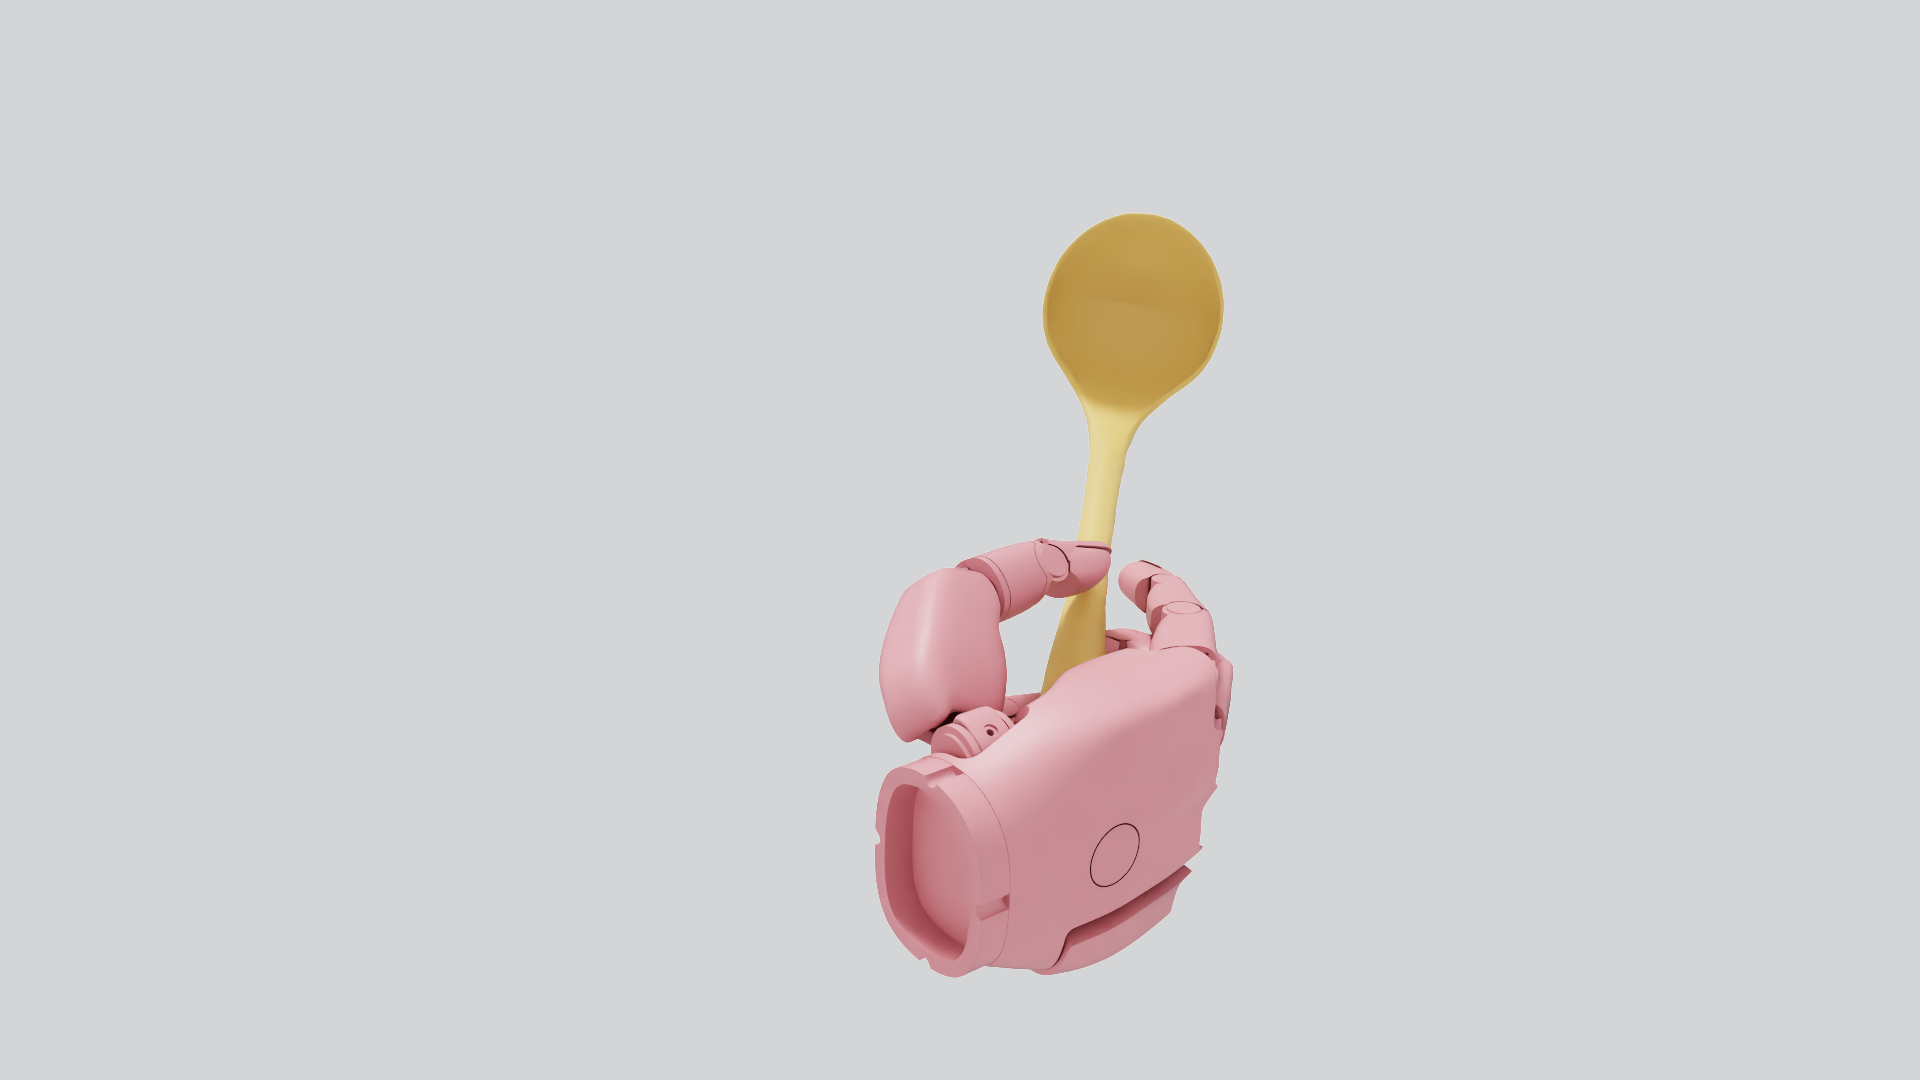
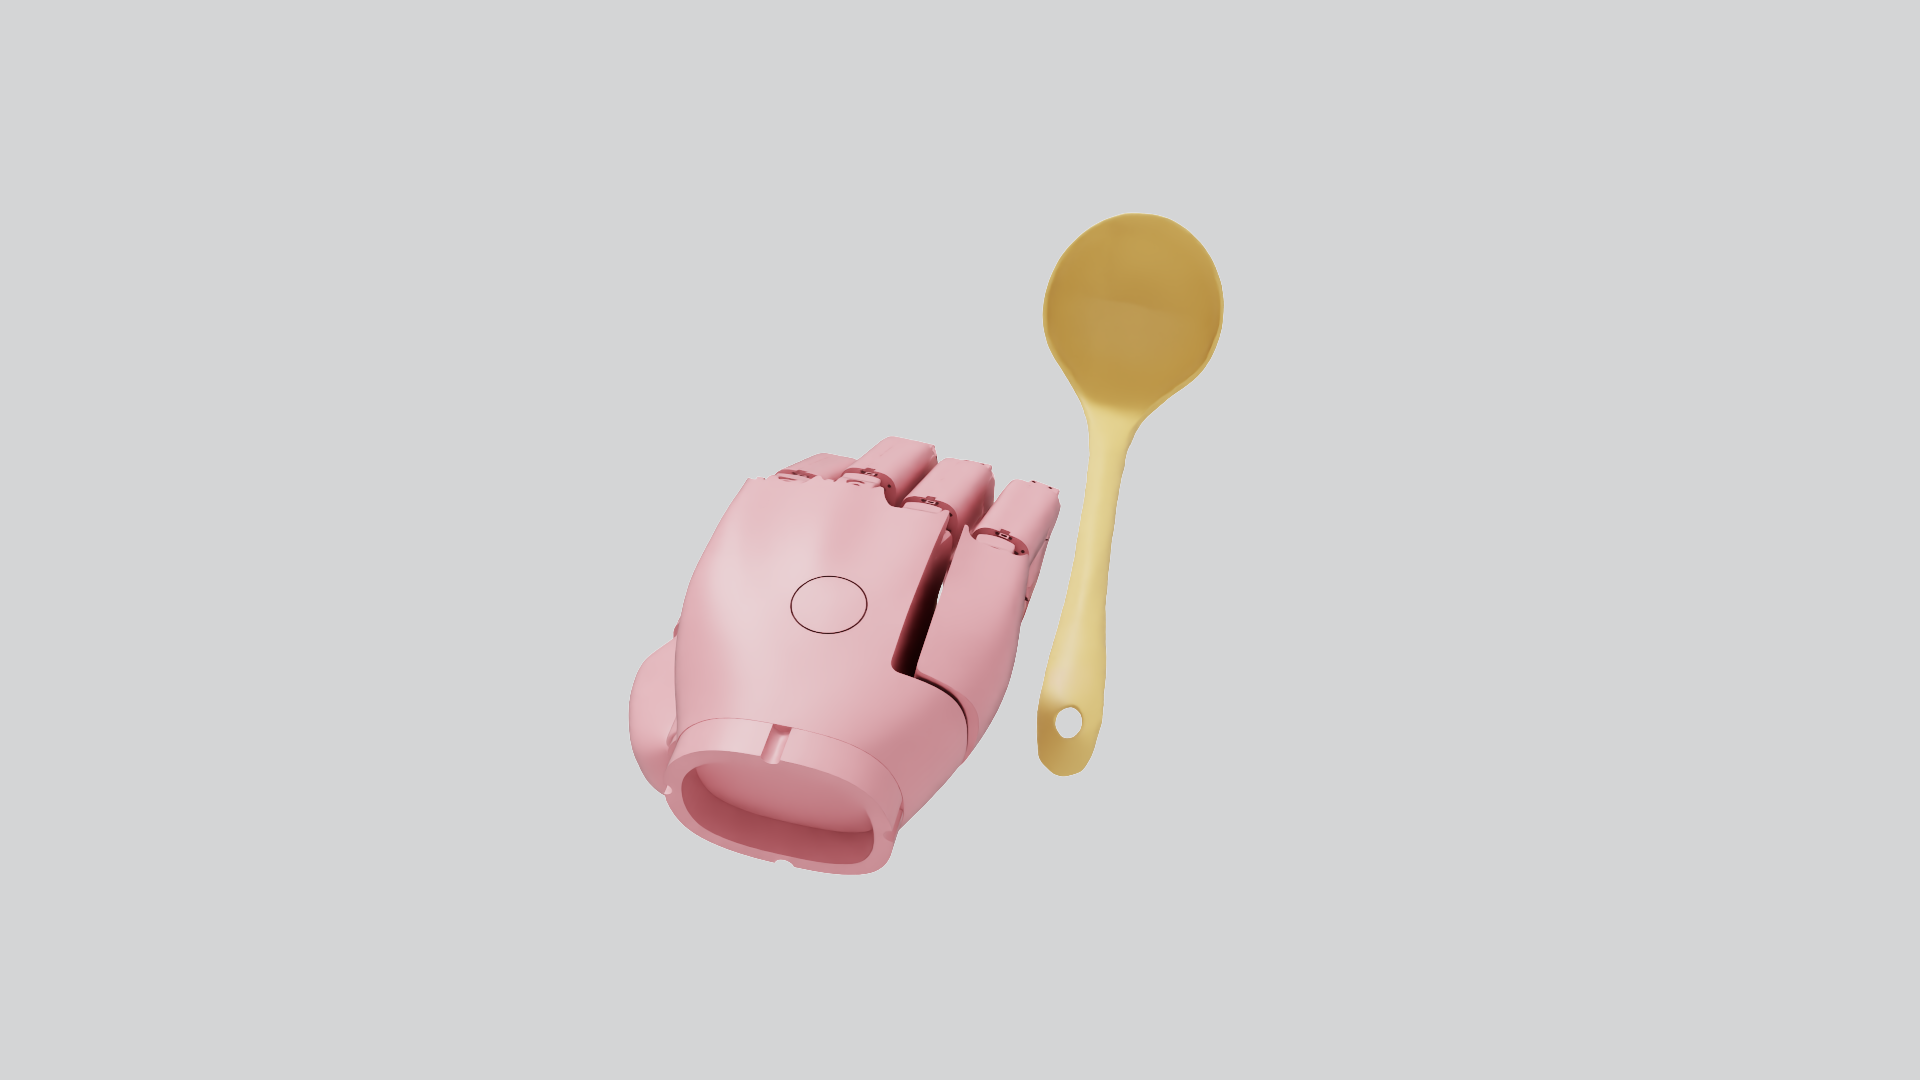
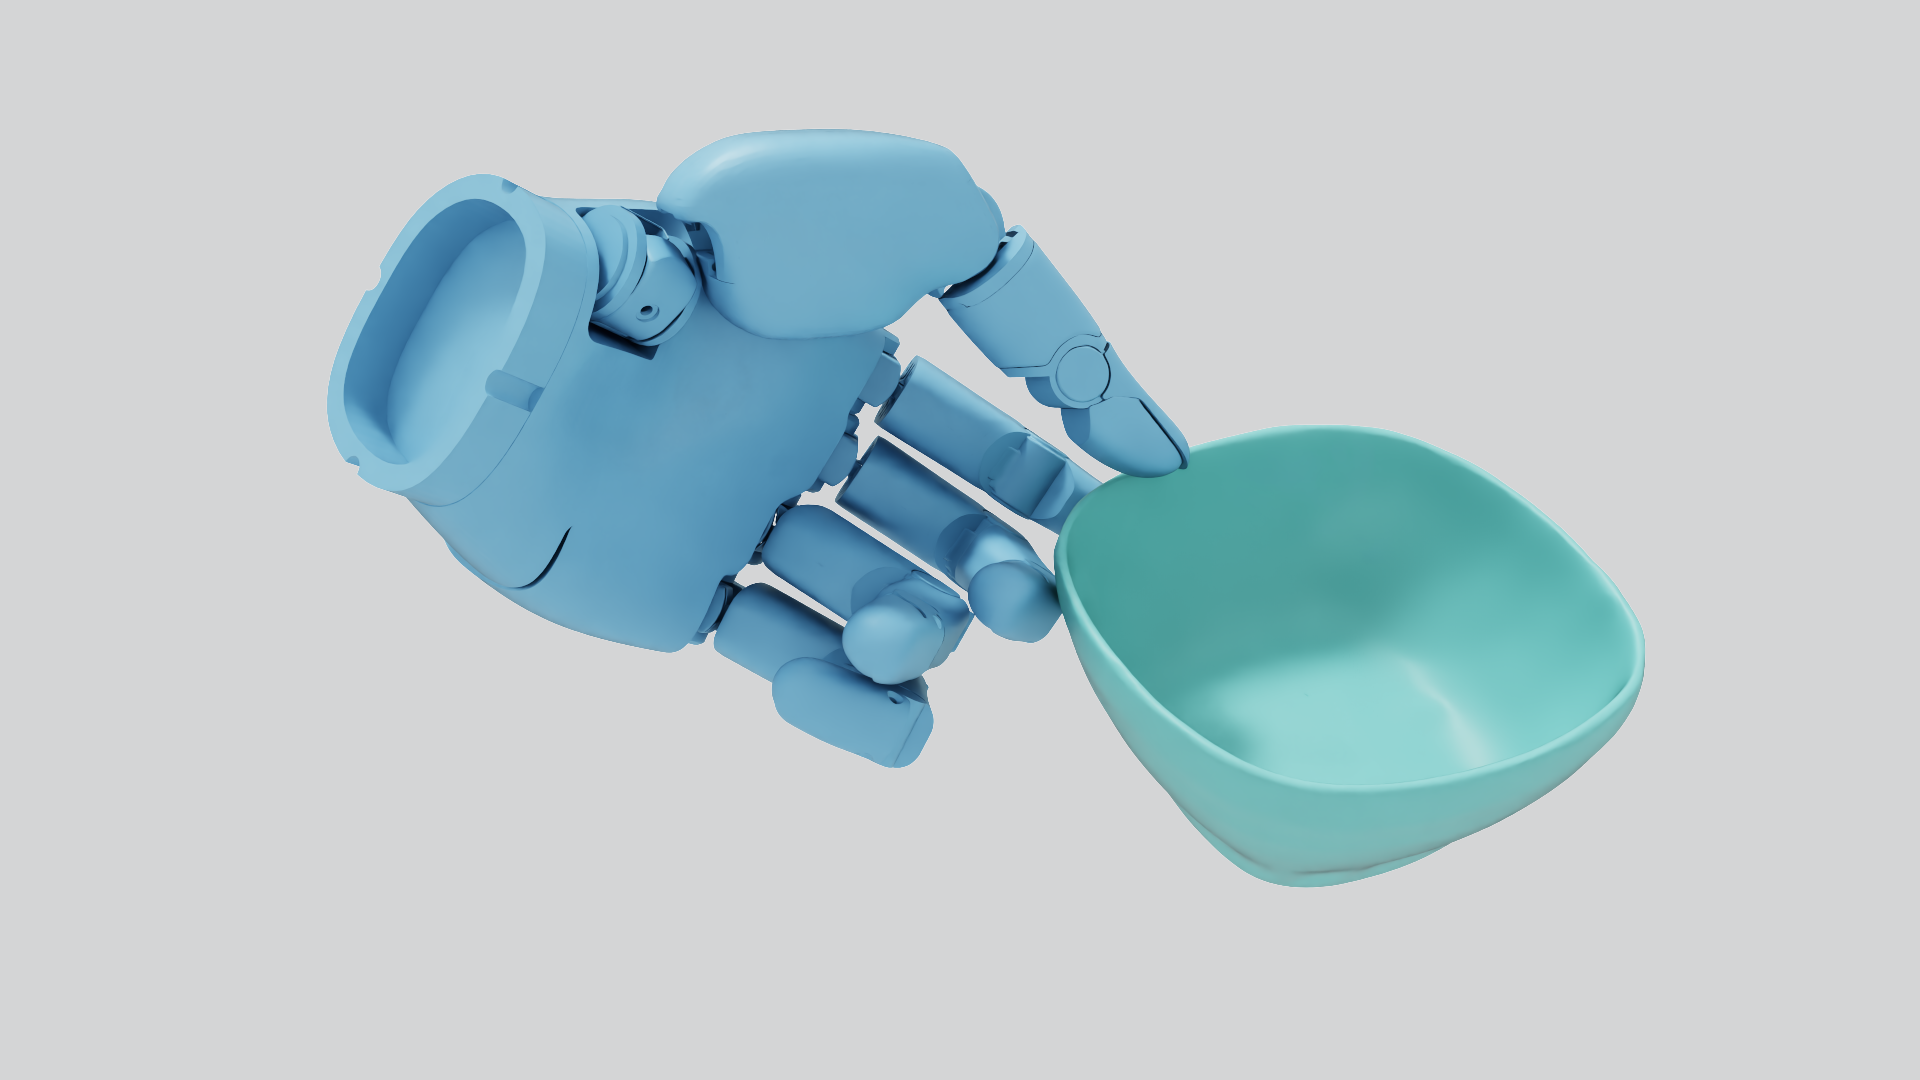
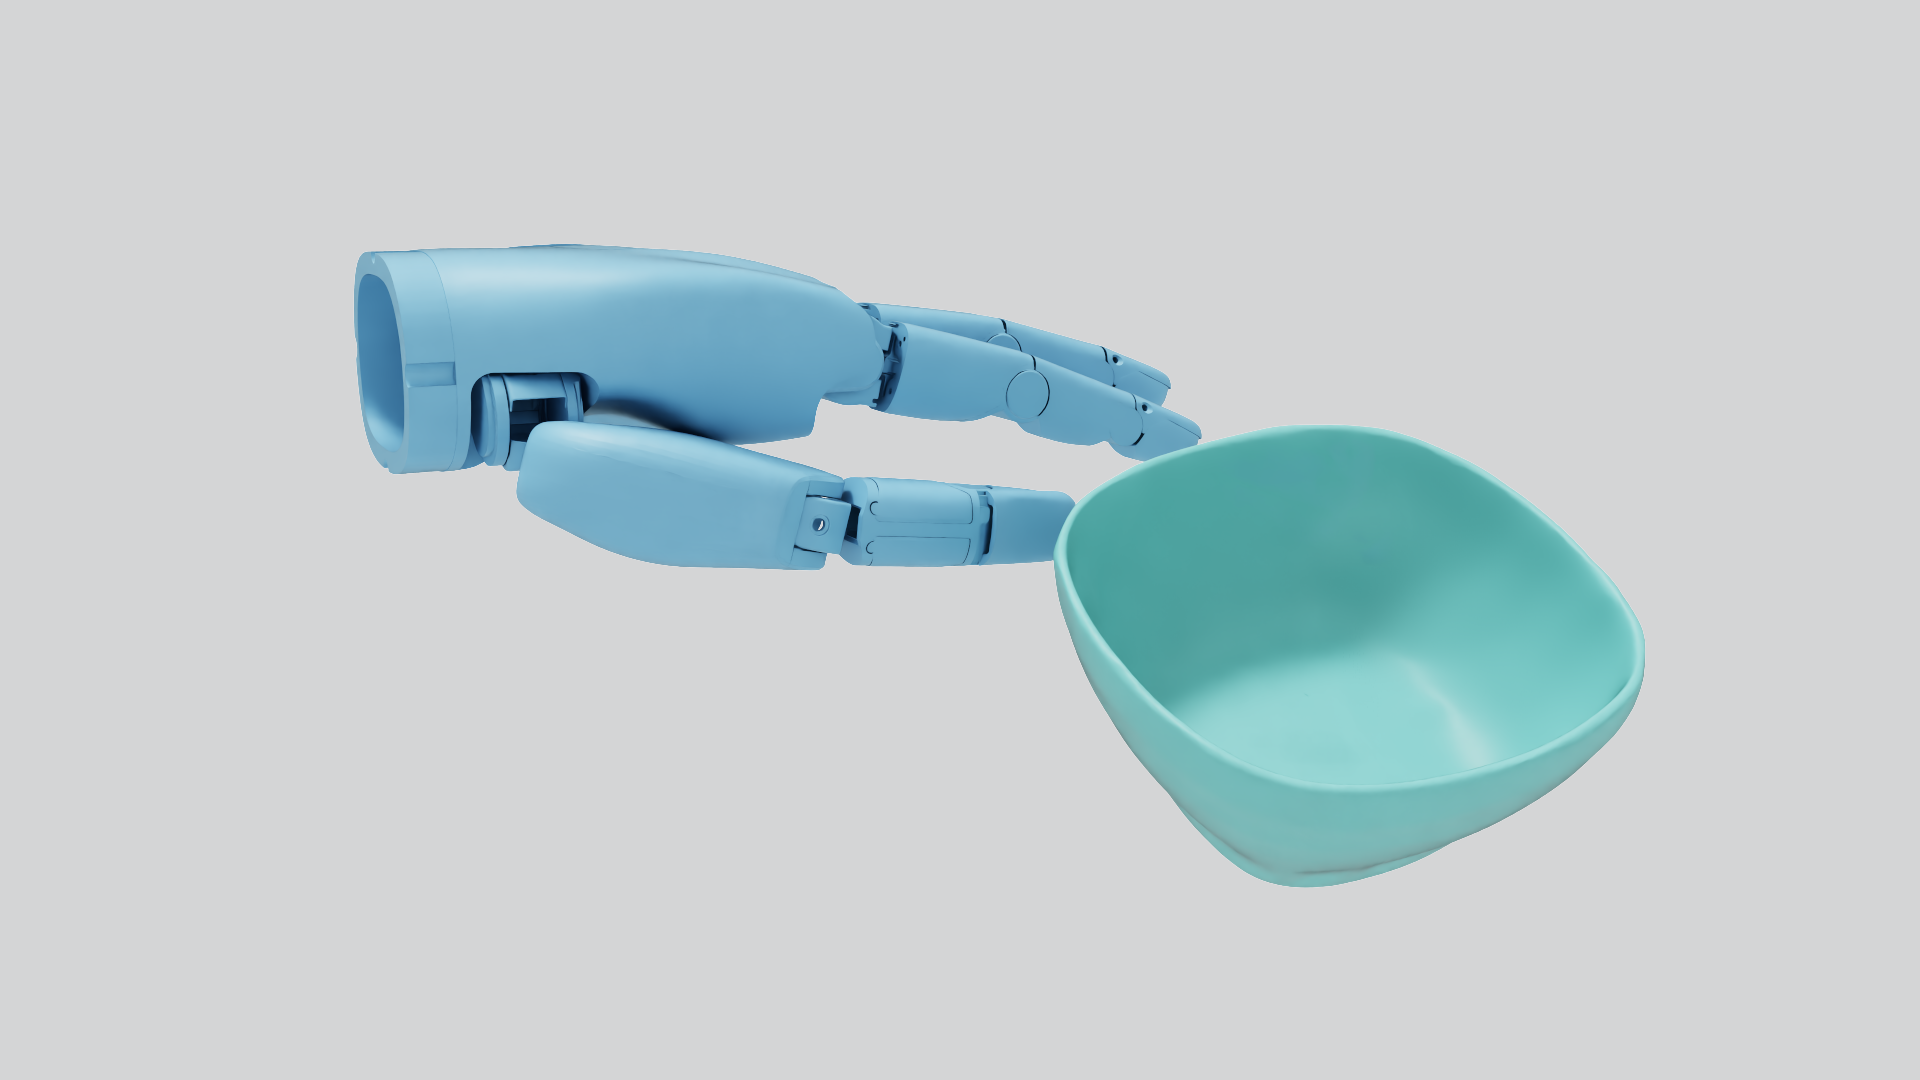
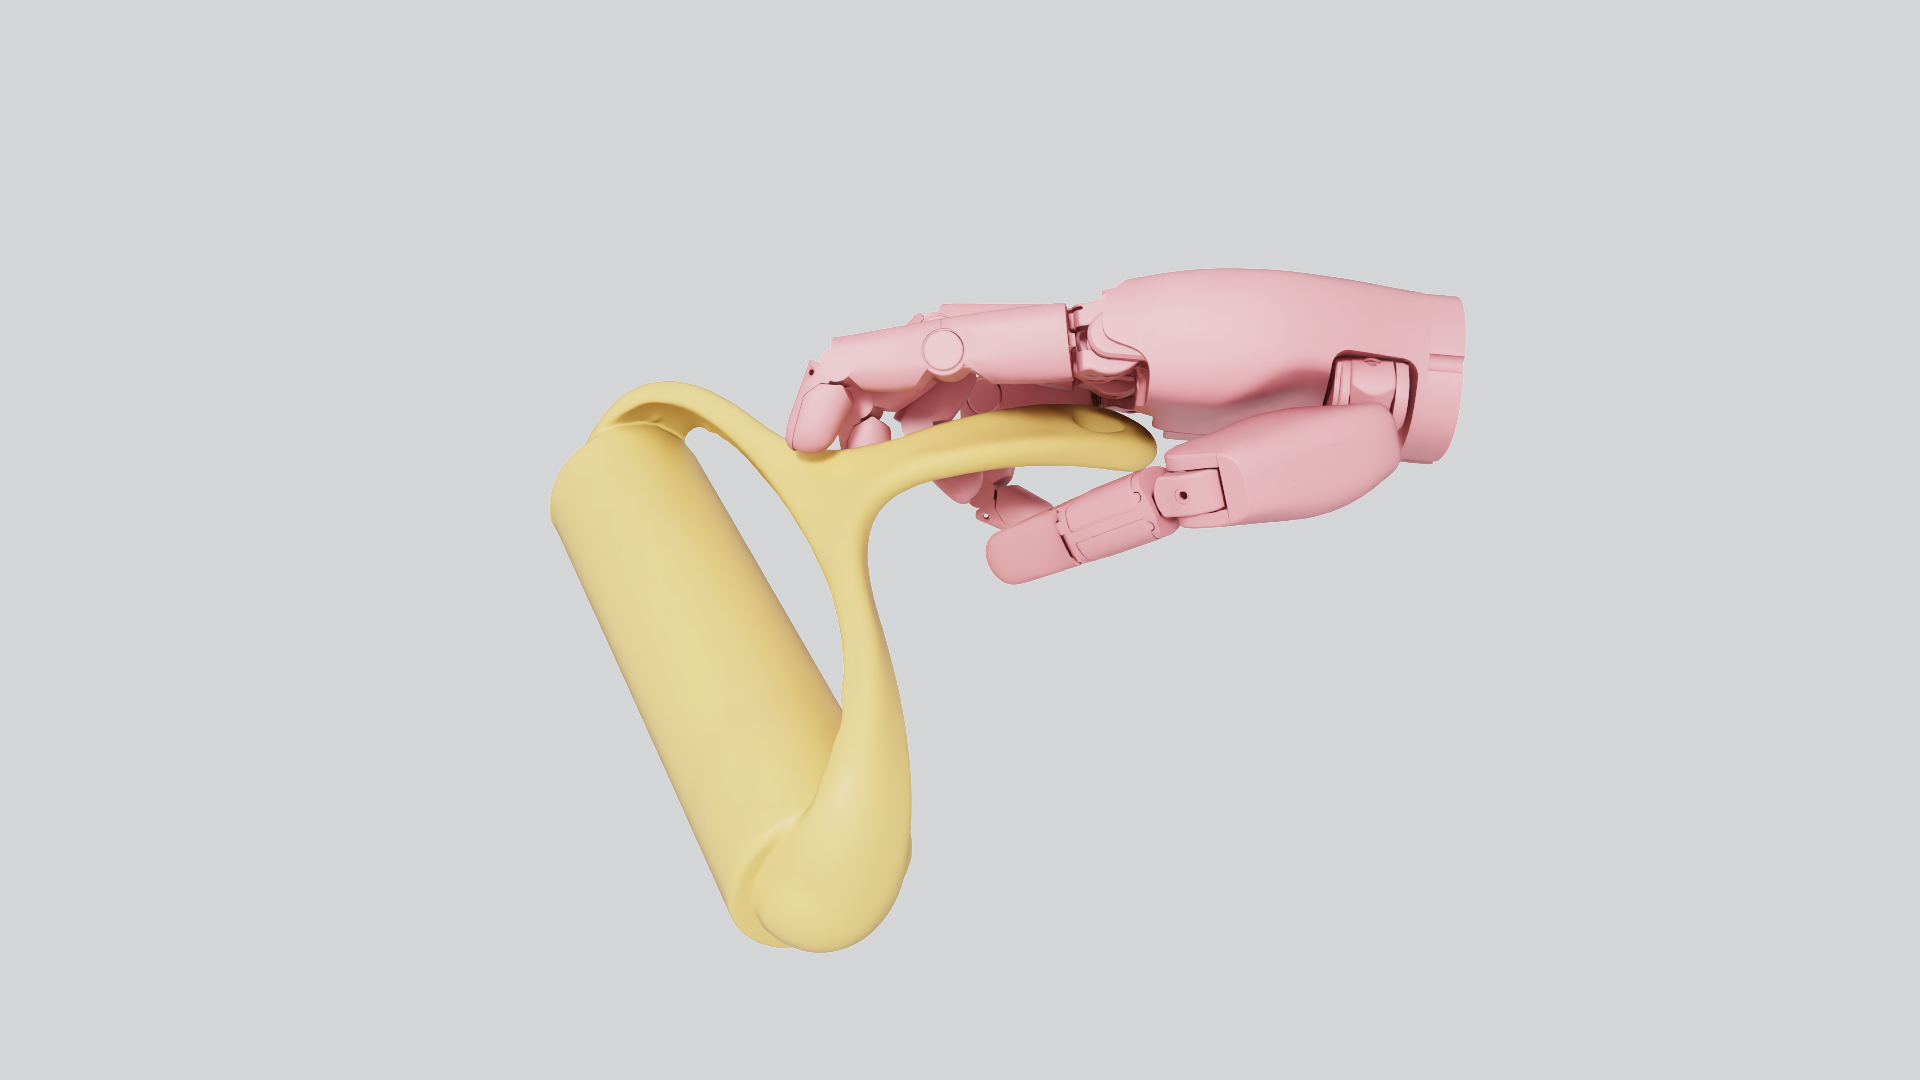
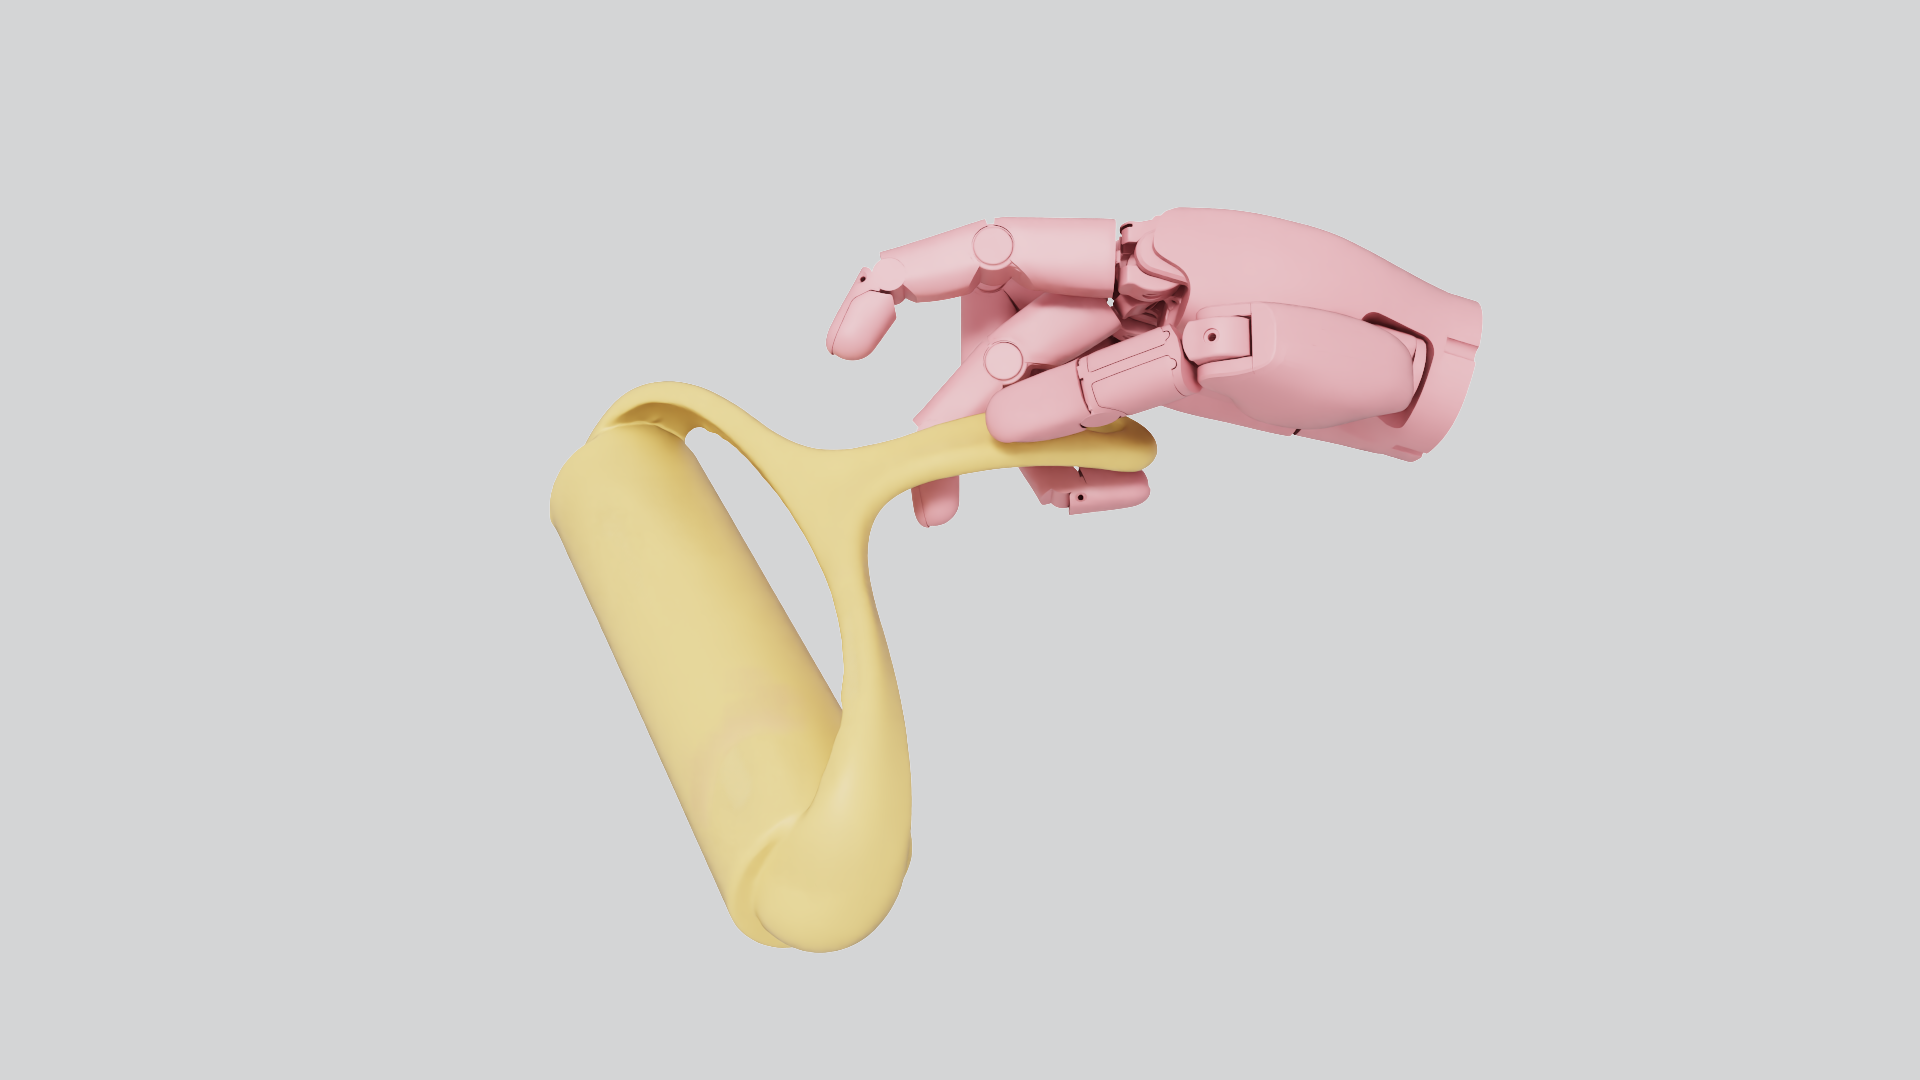
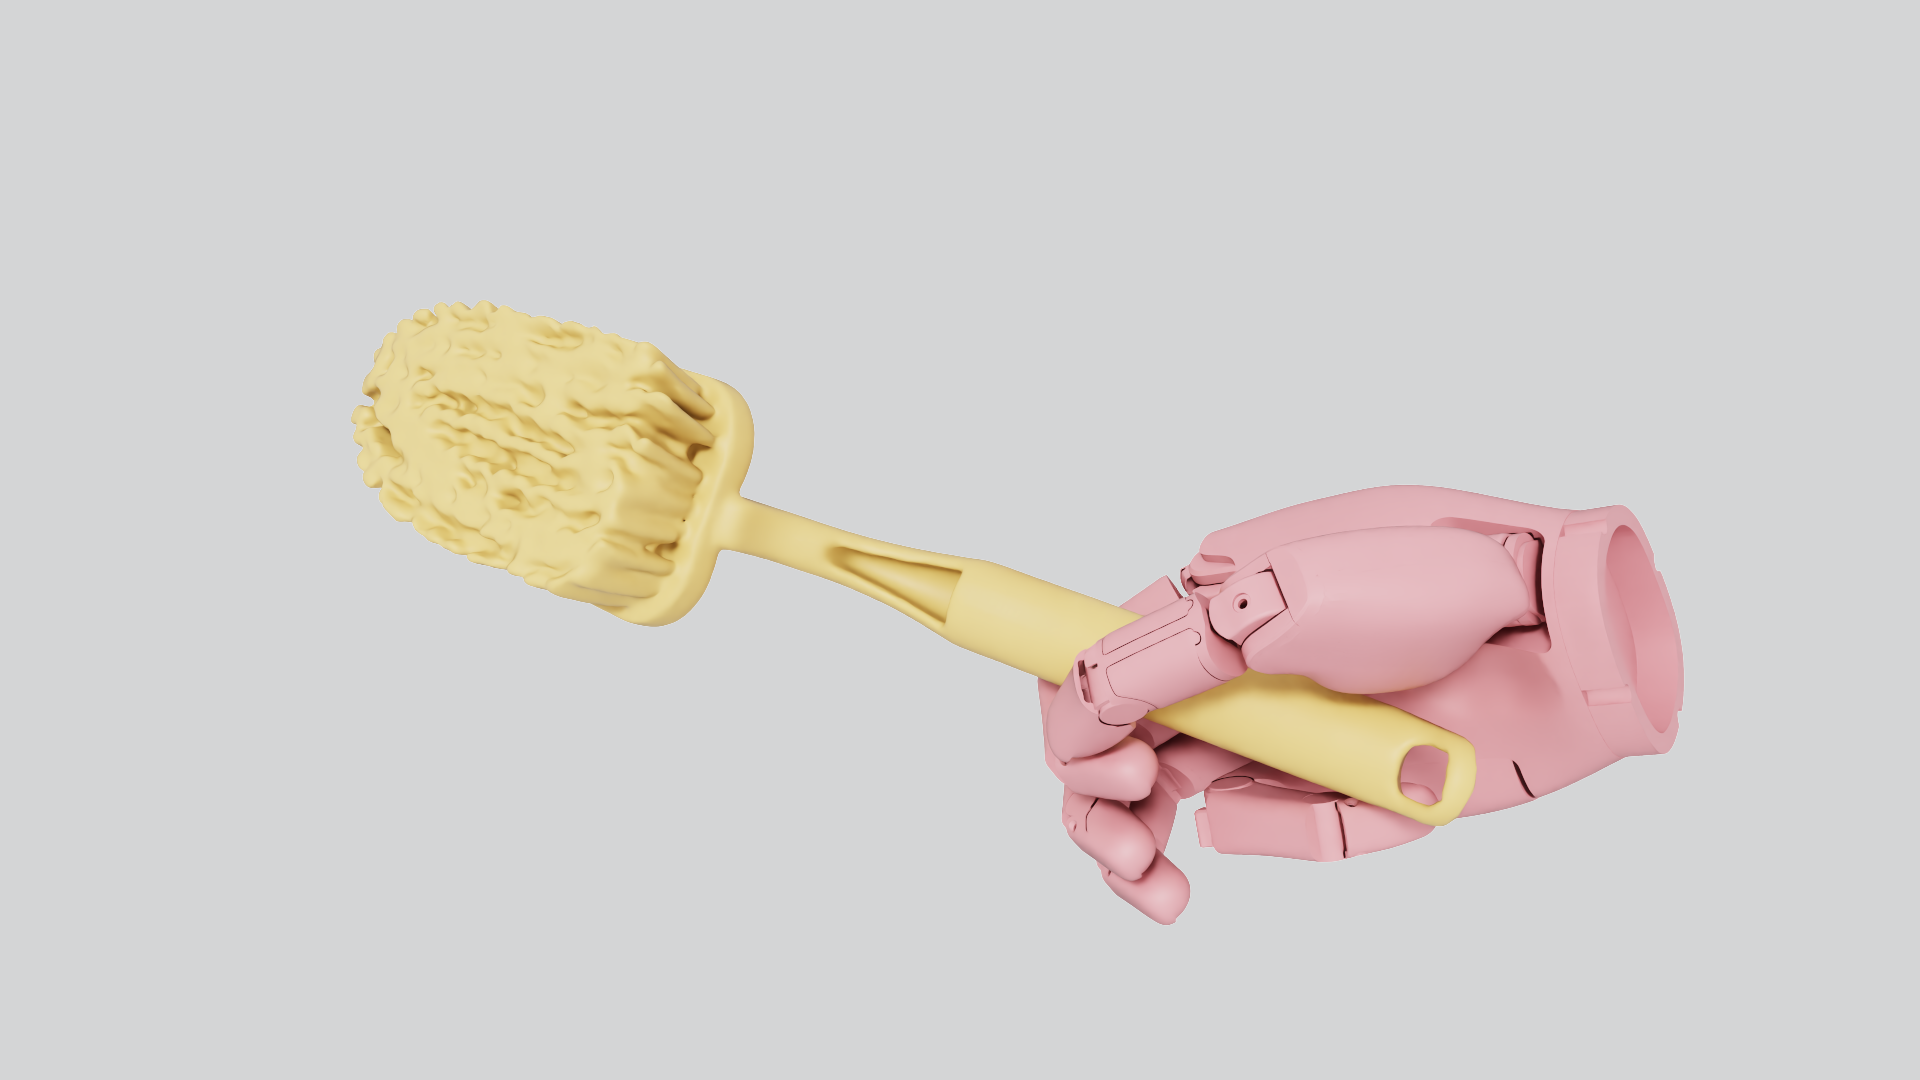
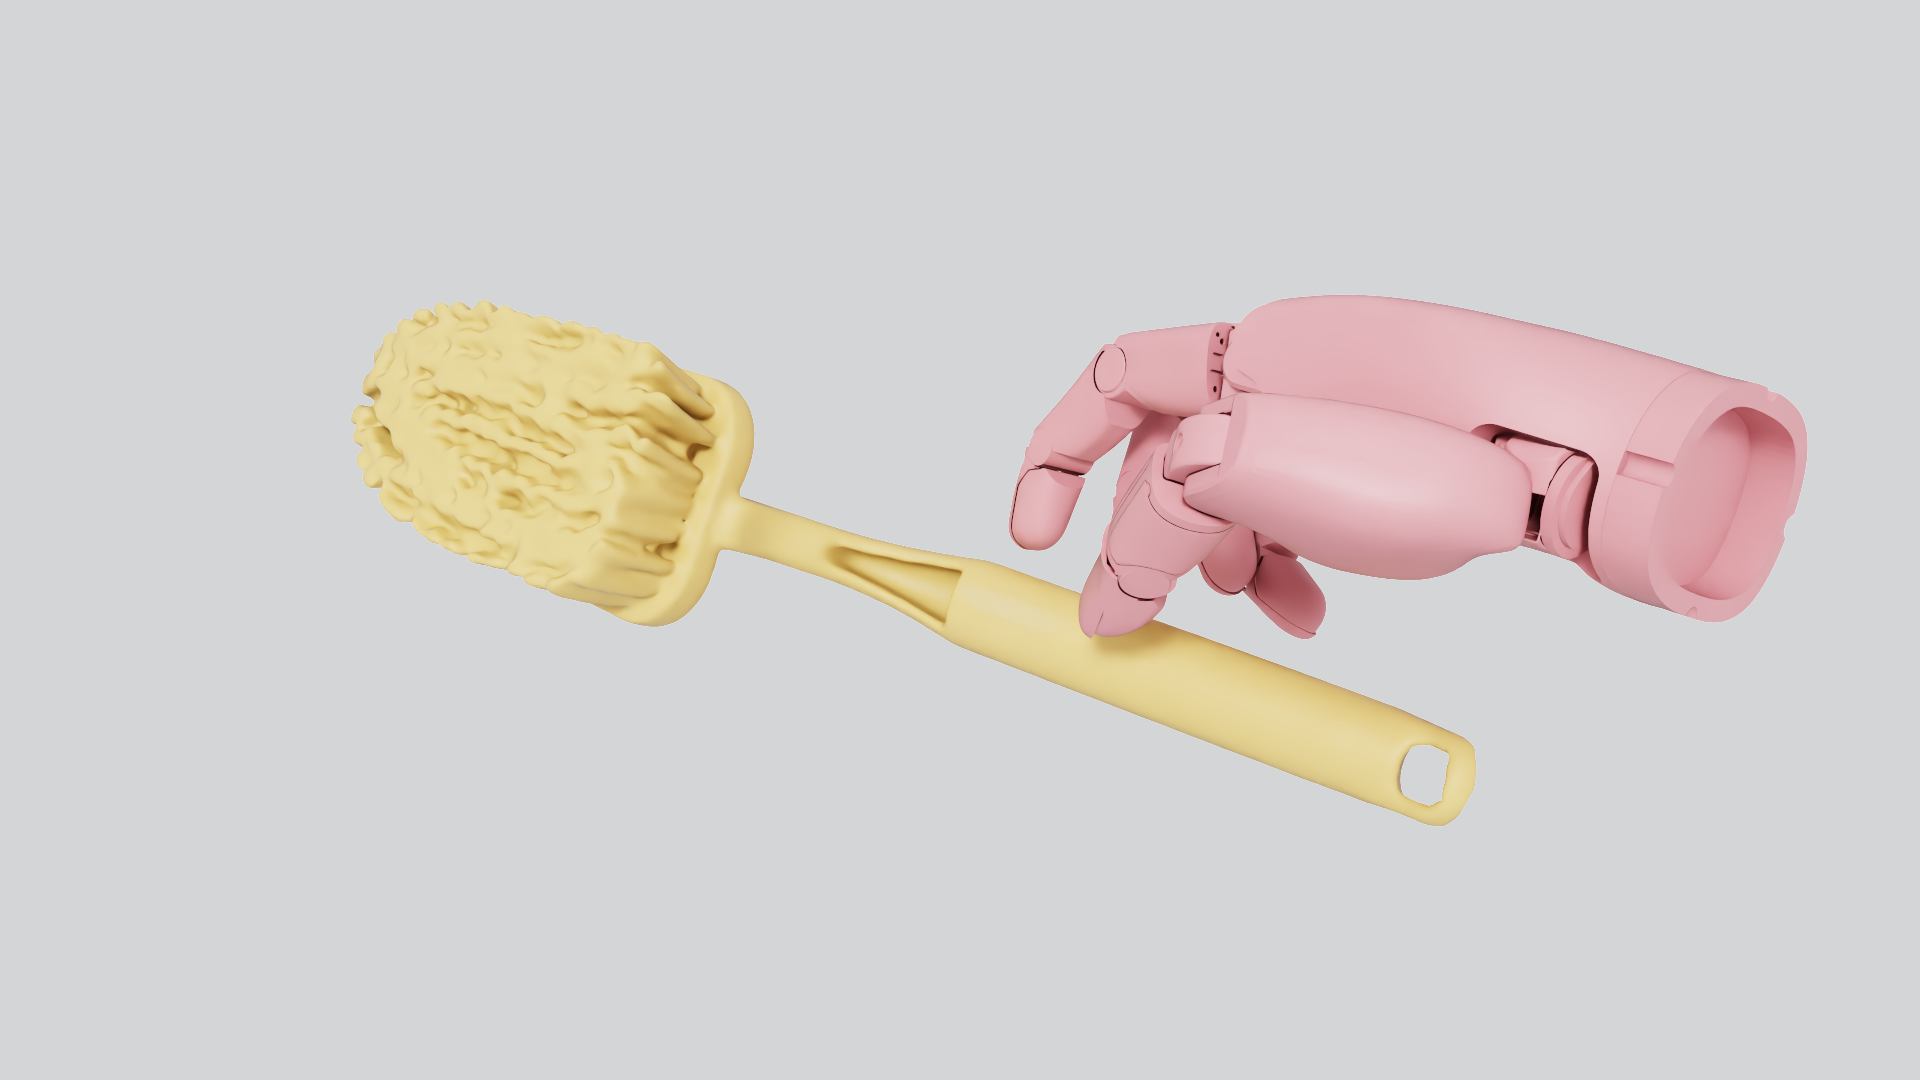
Noisy reconstruction and a change in embodiment can break hand–object contact. Instead of copying these contacts, EgoCPT searches for a robot-feasible way to realize the demonstrated object motion.
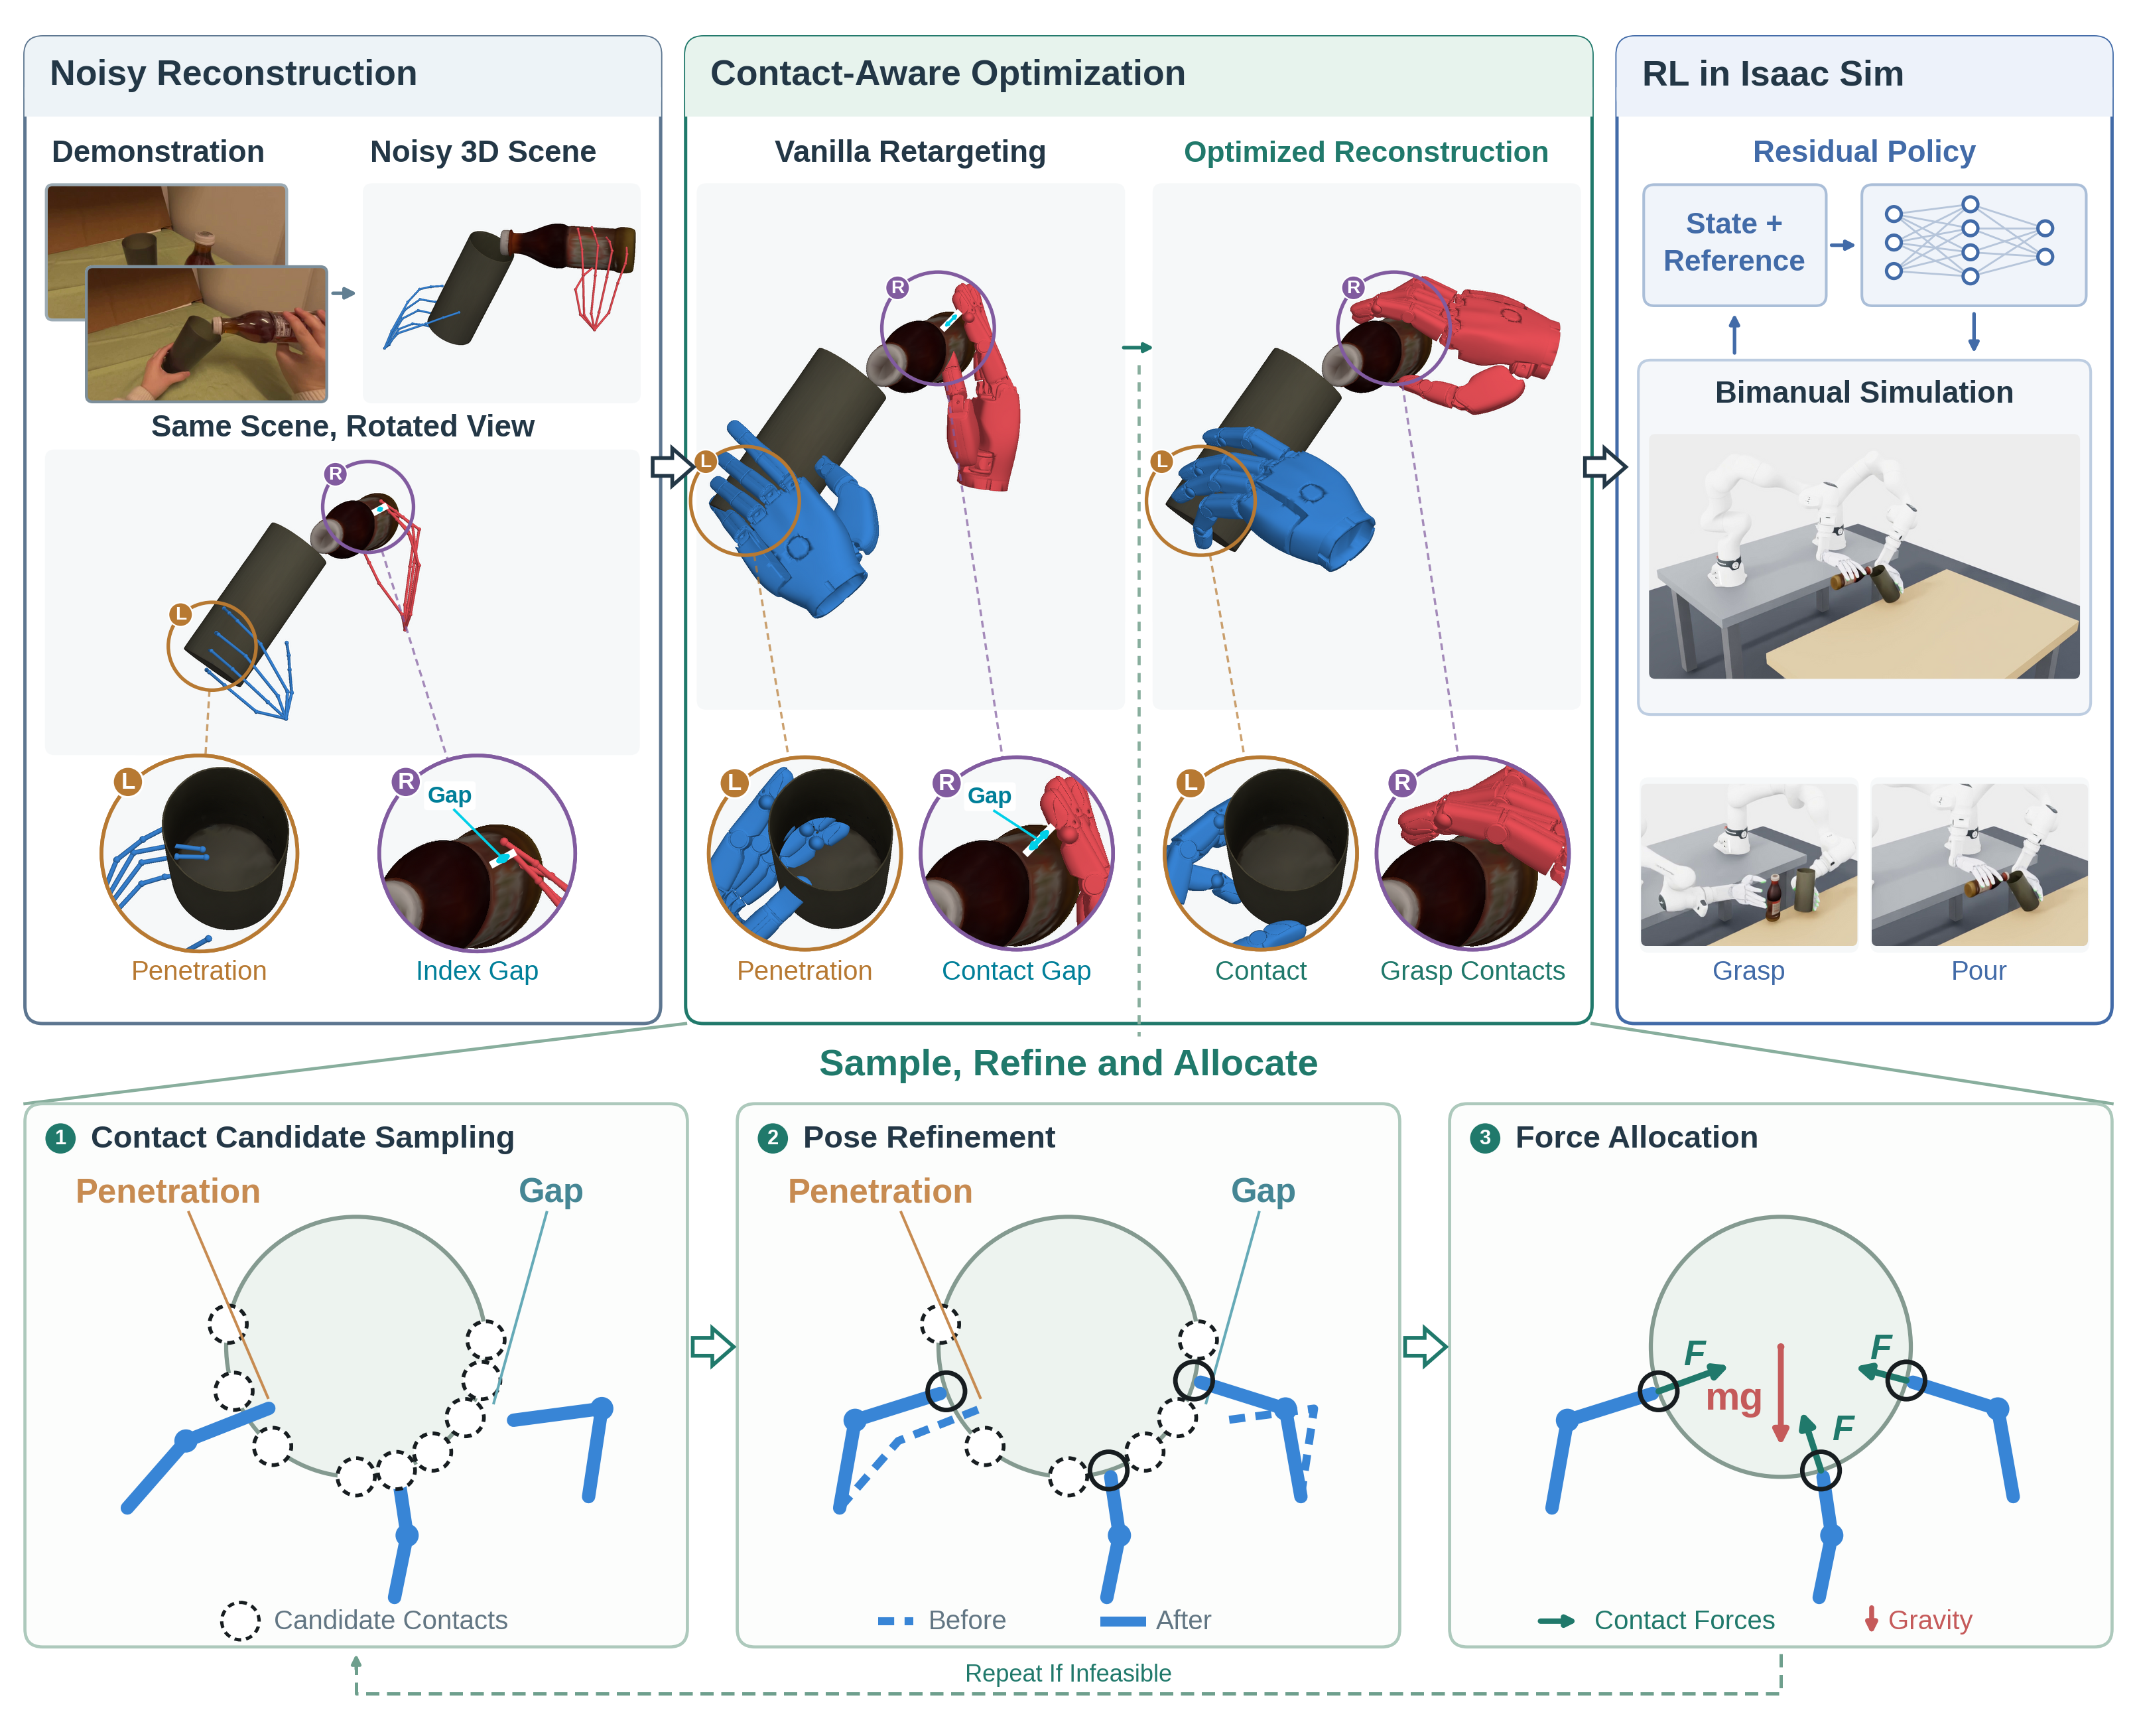
Search near the demonstrated hand gesture for contacts reachable by the robot.
Adjust the wrists and fingers to remove penetration and close contact gaps.
Find contact forces consistent with the target object motion, then refine again when needed.
Robot hand–object rollouts from egocentric demonstrations.
Visualized in Isaac Sim at 1×
More demonstration on TACO dataset
A selection of rollouts. Playback rates are indicated in each tile.
@misc{sun2026egocpt,
  title = {EgoCPT: Learning Dexterous Manipulation from a Single
           Ego-Centric Video with Contact-Aware Optimization},
  author = {Sun, Zhixin and Shi, Kairui and Ren, Tianao and
            Yang, Ming and Cutkosky, Mark and Xu, James Jingxi},
  year = {2026}
}